Current tag:linear motor
 DD Motor Servo System: How to Understand Mechanical Resonance and Solve Machine Vibration?This article explains the relationship between DD motor servo tuning, mechanical resonance, and servo bandwidth in direct drive motion systems. It examines why vibration and instability can occur even after repeated servo parameter adjustments, and explains how mechanical stiffness, moving mass, bearing conditions, load distribution, and structural geometry affect resonance frequency. The article also compares approaches for high- and low-frequency resonance, explains when digital notch filtering can be effective, and provides a practical tuning strategy for engineers working with DD motors, direct drive torque motors, and linear motors.
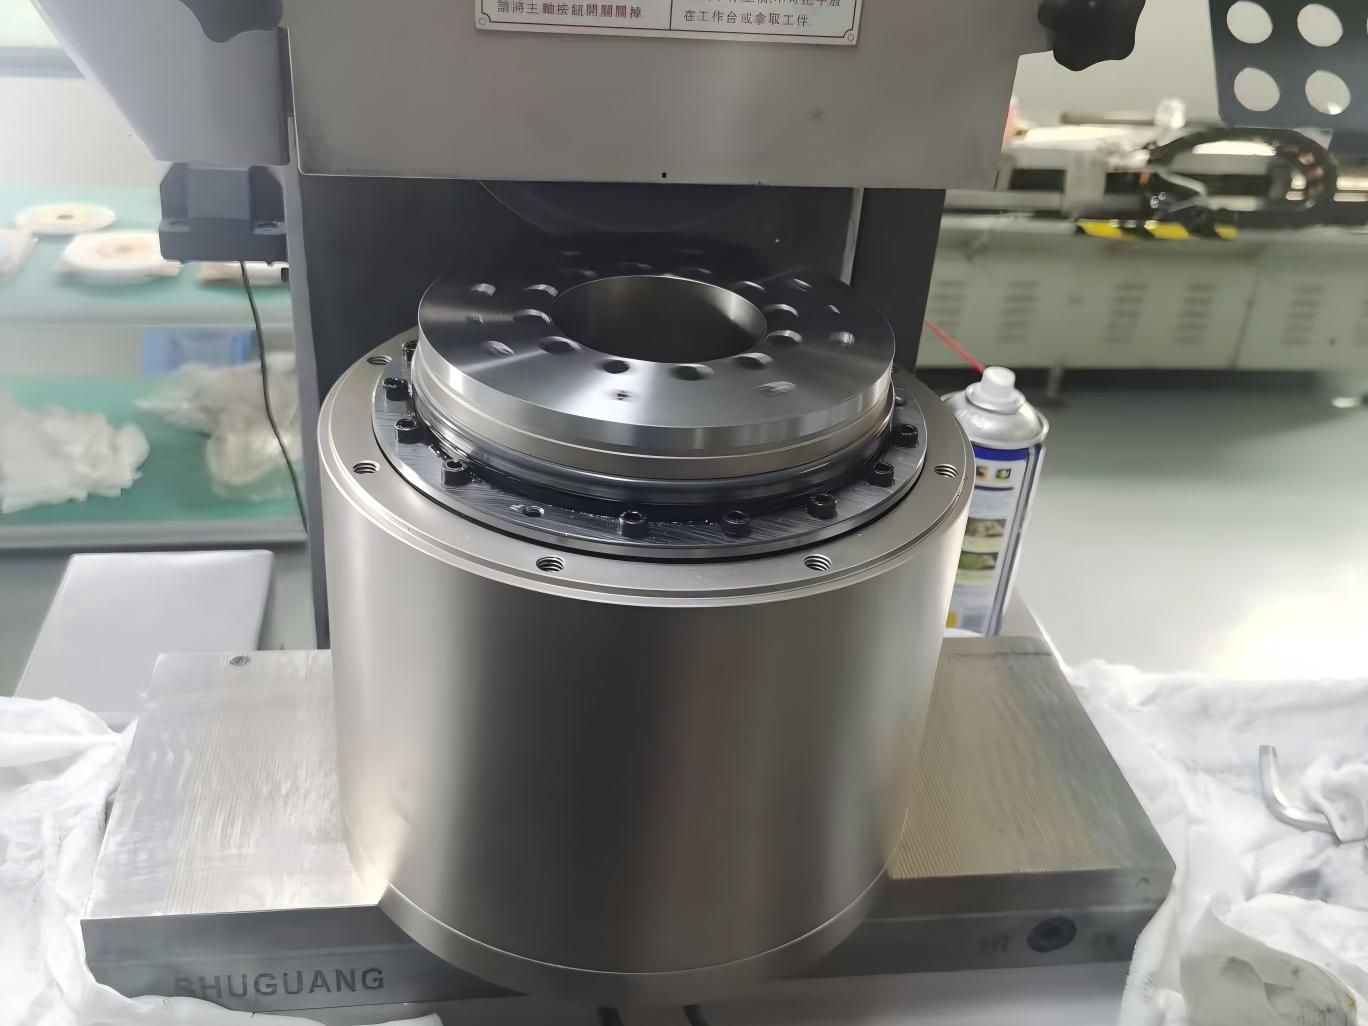
- What is a DD Motor? How to Select a DD Motor?DD motor, full name Direct Drive motor, is a motor that directly drives the load without using reduction devices such as gears, belts or ball screws. Its working principle is based on high torque output, allowing it to be directly connected to the moving equipment, thereby eliminating the need for intermediate connection parts such as fasteners, gearboxes and belts.
- Why do high-end 5-axis CNC machines choose DD motors instead of servo motors?DD motors are widely used in high-end equipment such as 5-axis CNC machines because of their high precision, fast dynamic response, low maintenance requirements, and long service life.
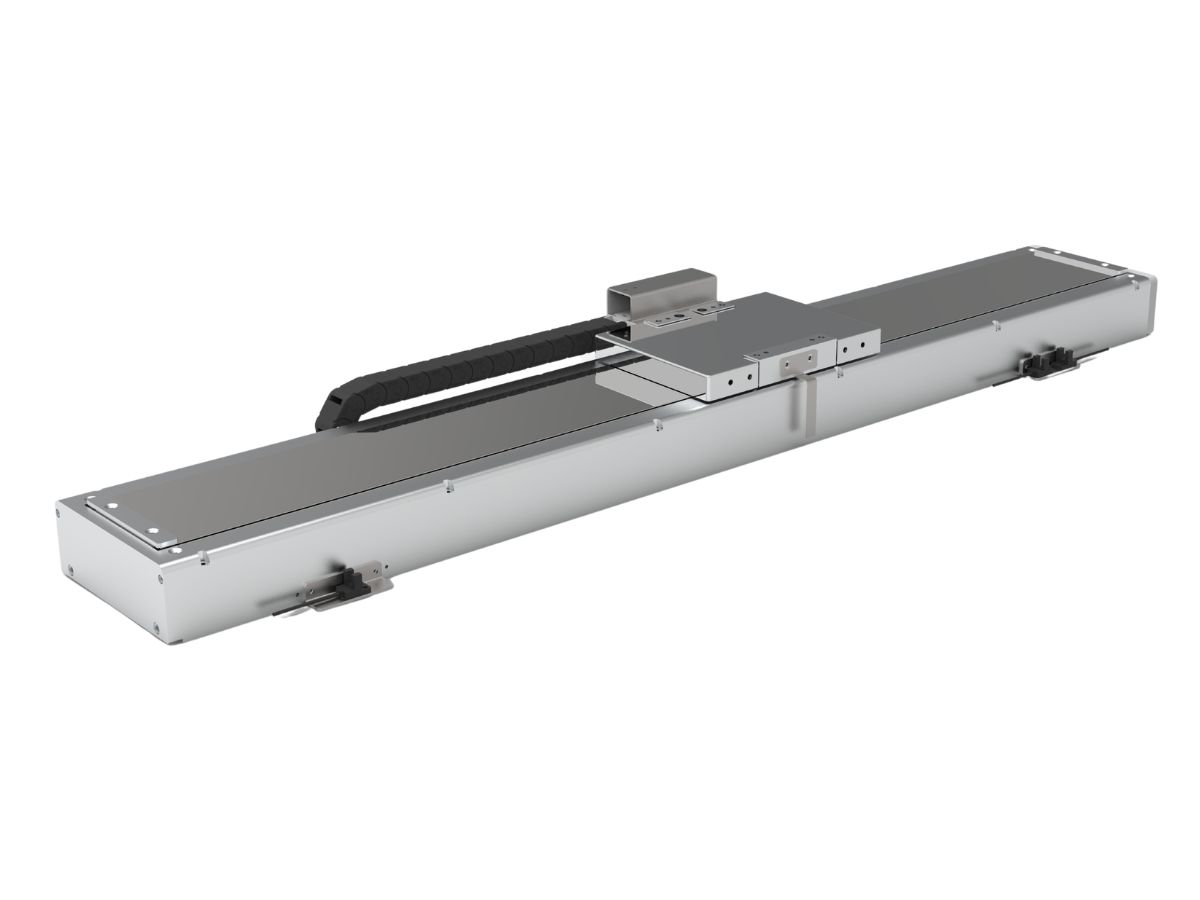
- Fully Enclosed Direct Drive Linear Motor Actuator for High Hygiene Standards DevicesA fully enclosed direct drive linear motor actuator features a structure entirely sealed within a housing, effectively preventing dust, water vapor, and other contaminants from entering the internal mechanisms, thereby extending its service life. Typically manufactured from stainless steel, these modules offer excellent corrosion resistance and durability. They are ideal for industries with high hygiene standards, such as food processing, pharmaceuticals, and medical devices.