How to Choose Harmonic Joint Actuators for a 7-DOF Robotic Arm?
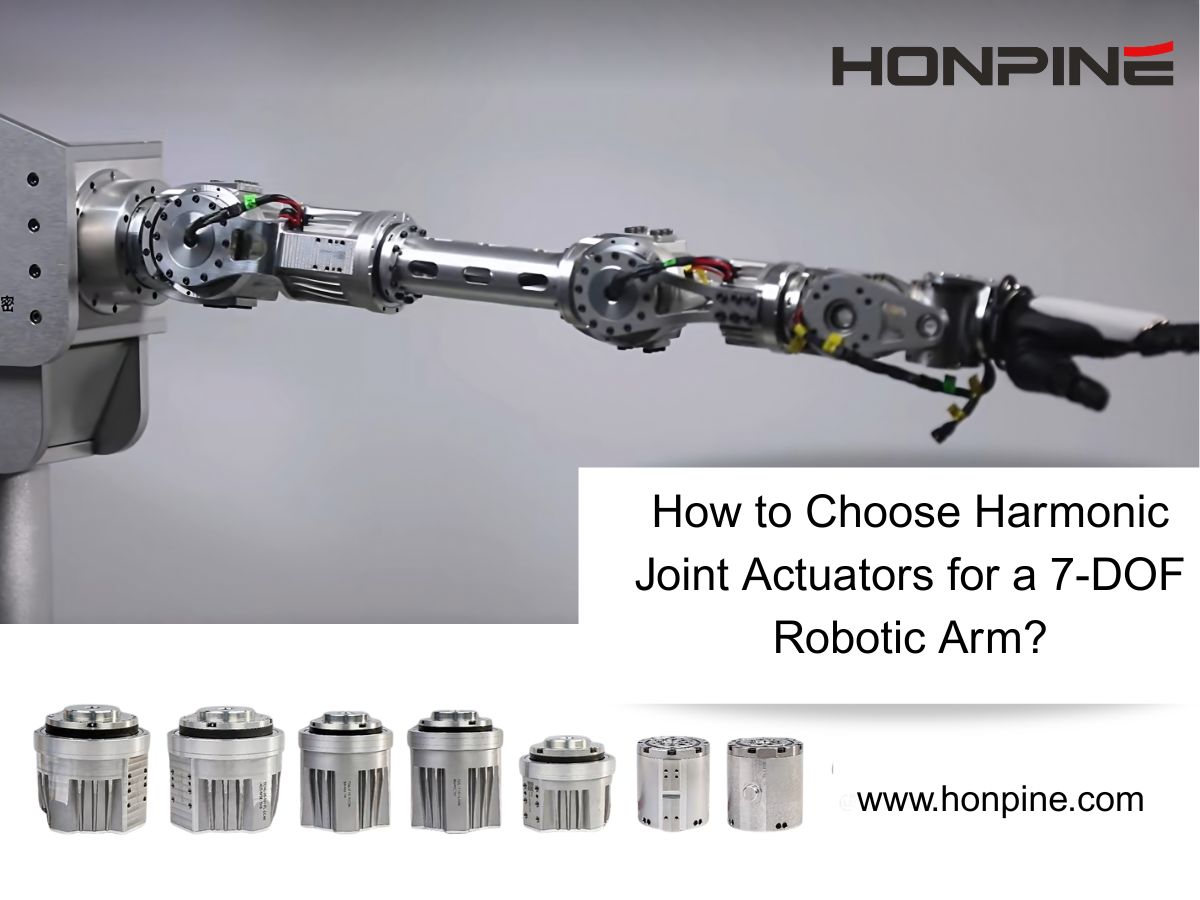
Hello, I’m Theodore Li, Technical Director at HONPINE. In this article, I’ll explain how to select harmonic joint actuators for a seven-degree-of-freedom robotic arm.
A seven-degree-of-freedom, or 7-DOF, robotic arm has one additional degree of freedom beyond the six generally required to control an end effector’s position and orientation in three-dimensional space. This additional degree of freedom is known as kinematic redundancy.
With appropriate mechanical design and control algorithms, this redundancy provides greater motion flexibility, supports obstacle avoidance and singularity avoidance, and enables compliant movements that resemble those of a human arm.
These capabilities make 7-DOF robotic arms valuable for research and development in medical robotics, precision assembly, flexible processing, and operations in challenging environments.
So, how should you choose the joint modules for a 7-DOF robotic arm?
How to Select Harmonic Joint Actuators for a 7-DOF Robotic Arm?
Match Each Actuator to the Joint’s Load Requirements
Within the same actuator series, a larger frame size generally offers greater output torque and can support higher joint loads. However, the actuator should be selected according to the requirements of the individual joint rather than its model number alone.
In many robotic-arm configurations, joints farther from the end effector must support the payload together with more of the arm’s downstream components. As a result, these joints often require greater output torque.
The shoulder joint is a typical example. Because it supports much of the arm and operates at a considerable distance from the end-effector load, a larger harmonic joint actuator is often selected for this position.
Wrist joints, by contrast, require careful consideration of wrist bending and rotation, tooling loads, and the overall mass of the distal assembly. Smaller, lighter joint modules are often appropriate when they can meet the required torque and motion specifications.
The selection principle is to calculate the load requirements of each joint and match the actuator accordingly—not simply to use the same module throughout the arm.
Example: HONPINE TCHL Harmonic Robotic Actuators
To illustrate this approach, consider a 7-DOF robotic-arm configuration using HONPINE TCHL Series harmonic robotic actuators.
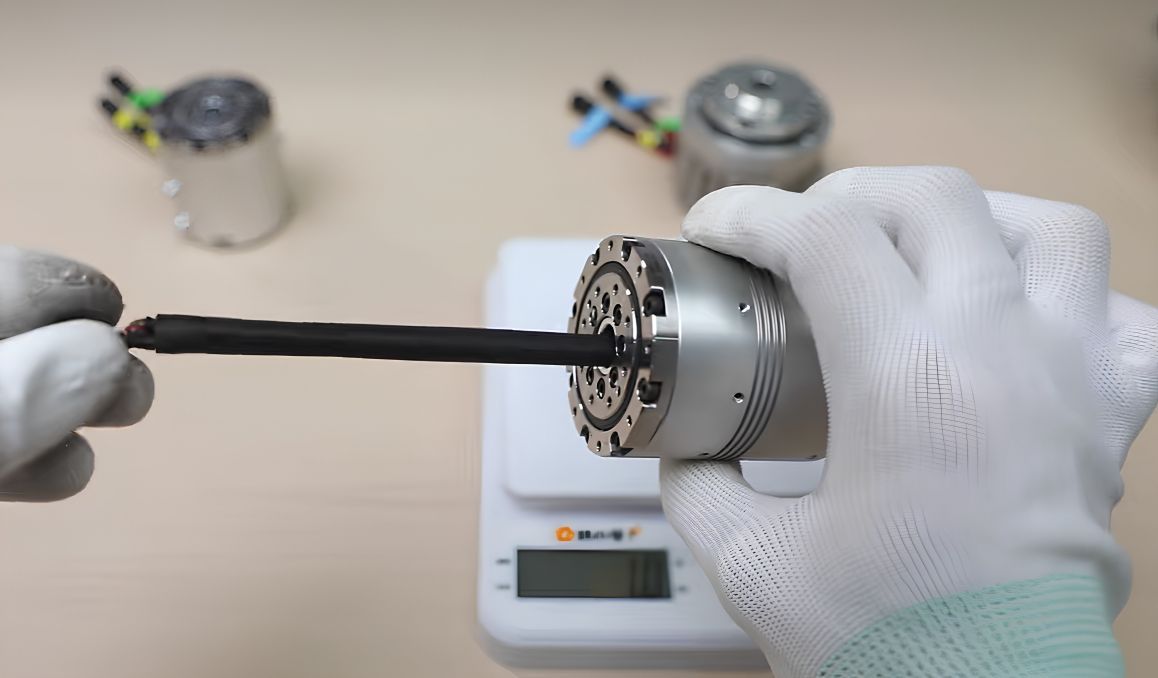
In this example, the shoulder uses a TCHL 20 joint module, while the wrist uses a TCHL 14 joint module.
The TCHL 14 features a compact, lightweight design with a hollow structure and a passage for cable routing. These characteristics make it a candidate for space-constrained wrist and robotic neck assemblies, where reducing distal mass is an important design objective.
This configuration illustrates the selection approach; it is not a universal recommendation for every 7-DOF robotic arm.
Why Do 7-DOF Surgical Robotic Arms Require More Advanced Harmonic Joint Modules?
A seven-degree-of-freedom redundant design, combined with suitable motion-planning and obstacle-avoidance techniques, gives a surgical robotic arm greater freedom to maneuver within a constrained workspace.
This flexibility helps the system address the positioning and access requirements of complex surgical procedures.
The robotic-arm capabilities discussed here also include hand-guided movement, motor-driven operation, API-based remote control, and automatic payload identification and compensation.
Supporting these functions places demanding requirements on joint sensing, control response, and system integration.
Torque Sensing and Responsive Force Control
For the force-controlled surgical-arm configuration discussed here, integrated high-precision torque sensors are an important part of the joint-module design.
These sensors provide feedback for force-sensitive control and collision detection. The performance figures described for this application include force-control accuracy of 0.5 N and a control update rate above 1,000 Hz.
The intended capability is a millisecond-scale response to contact forces, supporting delicate tasks such as insertion and controlled screw-driving.
These figures need to be associated with a defined configuration and test method. They should not be treated as specifications shared by every joint module or every complete robotic arm.
High-Bandwidth Torque Control and Compliant Motion
High-bandwidth force control can be summarized as:
High-bandwidth closed-loop torque control + compliant control algorithms
The objective is to make the system’s torque or force response sufficiently fast and accurate for the intended task.
An integrated high-resolution torque sensor provides the feedback needed for this control approach. The complete response also depends on how sensing, actuation, and control algorithms are integrated.
Redundancy-Based Motion Planning and Obstacle Avoidance
Redundancy-based obstacle avoidance can be described through three key elements:
Kinematic redundancy + null-space projection + hierarchical task-priority optimization
The additional degree of freedom gives the arm more options for adjusting its configuration while maintaining the required end-effector task.
Motion planning can coordinate several objectives with different priorities, such as:
1. Respecting joint limits to support safe operation.
2. Minimizing unnecessary joint motion and joint speeds, with energy efficiency as an optimization objective.
3. Maintaining a suitable arm configuration and managing proximity to singularities.
When sufficient redundant motion is available, the controller has greater freedom to accommodate secondary tasks such as obstacle avoidance. Whether all objectives can be satisfied still depends on the available workspace, joint limits, and task constraints.
HONPINE HAG Series Harmonic Joint Modules
For demanding motion-control applications, HONPINE offers the HAG Series harmonic joint modules.
The HAG Series is intended for applications requiring precise motion control and advanced force-sensing capabilities. Safe Torque Off (STO) is available as an optional feature, subject to the selected model and configuration.
This option can be considered as part of the complete robotic system’s safety design. It should not be interpreted on its own as confirmation that a joint module or robotic arm is approved for a particular medical application.
When evaluating an HAG harmonic joint module, confirm the required sensing performance, control interfaces, and available safety functions for the specific configuration.
Learn More About Harmonic Actuators for 7-DOF Robotic Arms
Choosing a harmonic joint actuator starts with understanding what each joint needs to do. Shoulder, elbow, and wrist joints can have different requirements for torque, weight, installation space, sensing, and control.
Contact HONPINE for more information about harmonic rotary actuators and joint modules for 7-DOF robotic arms.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
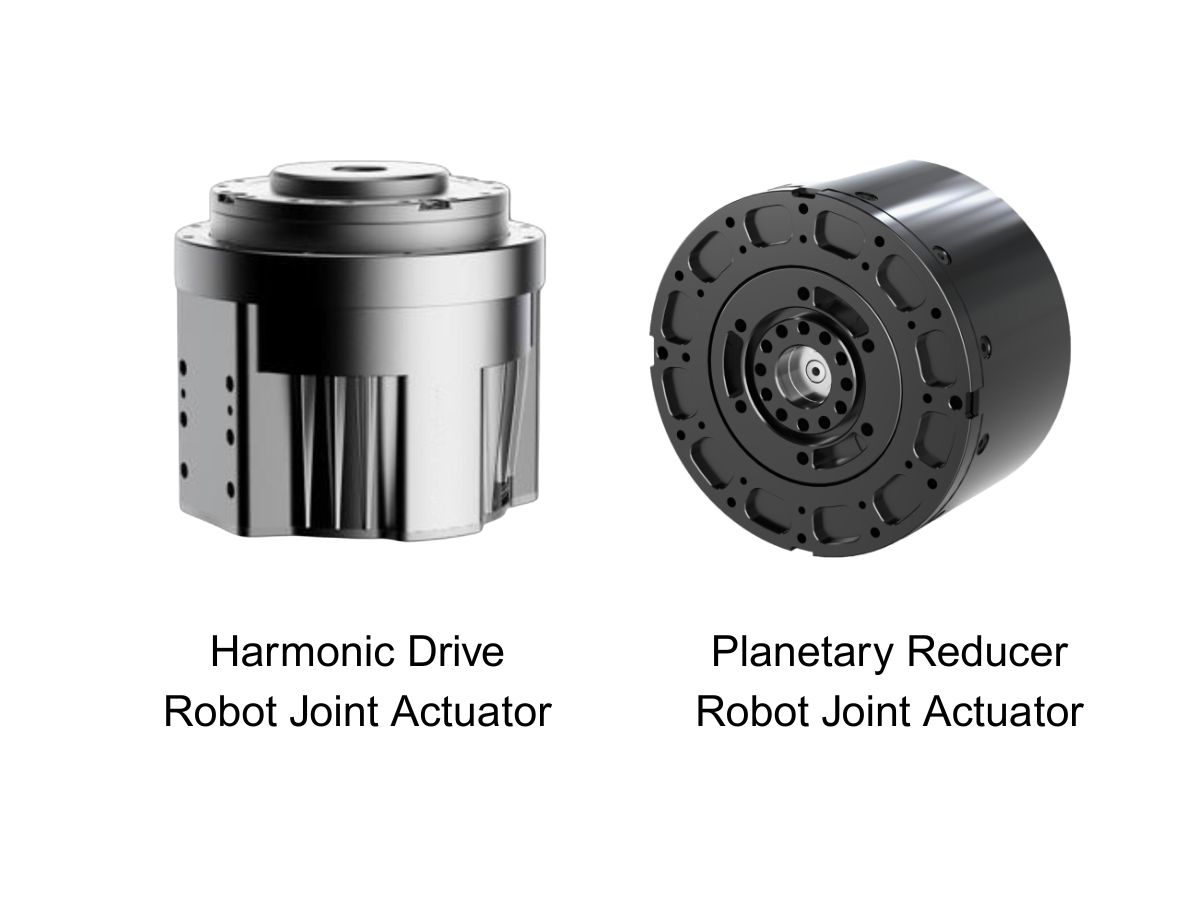
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
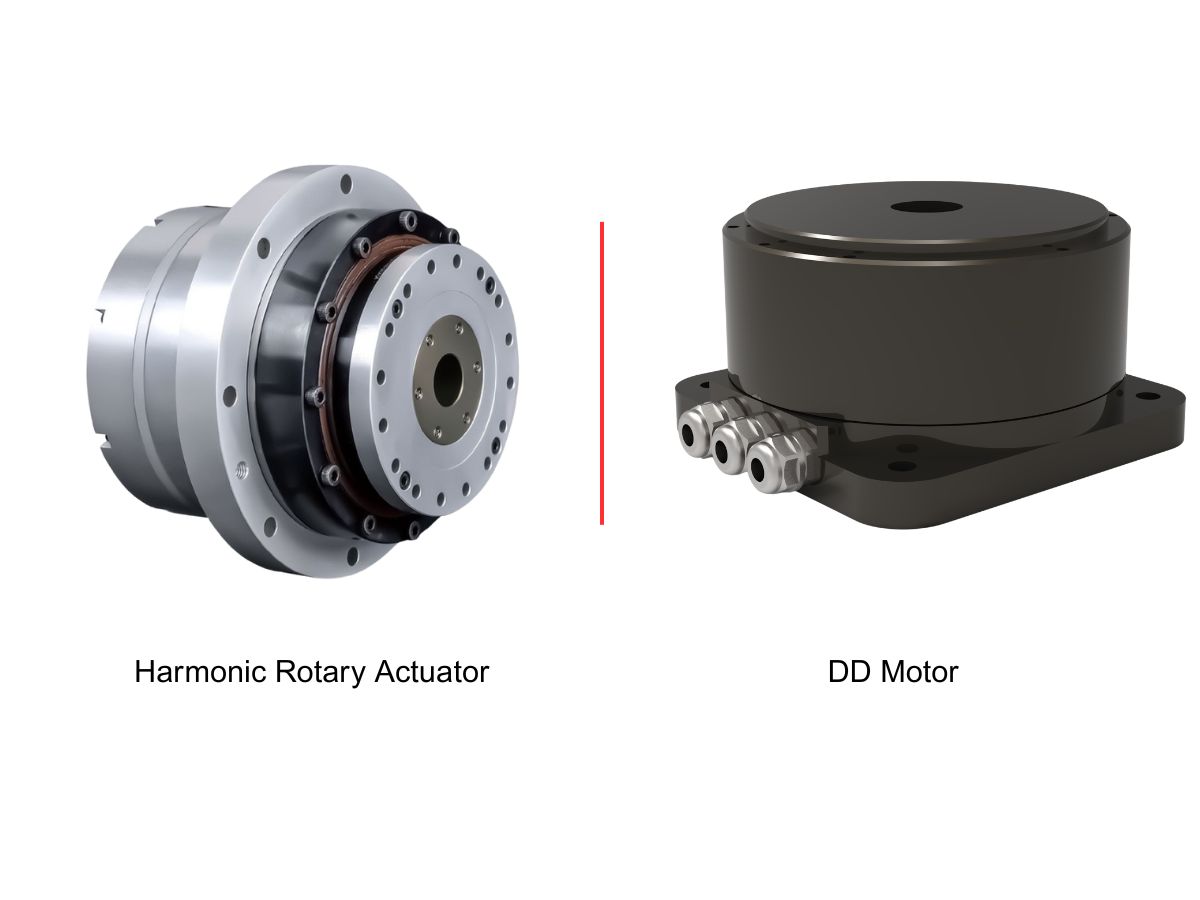
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
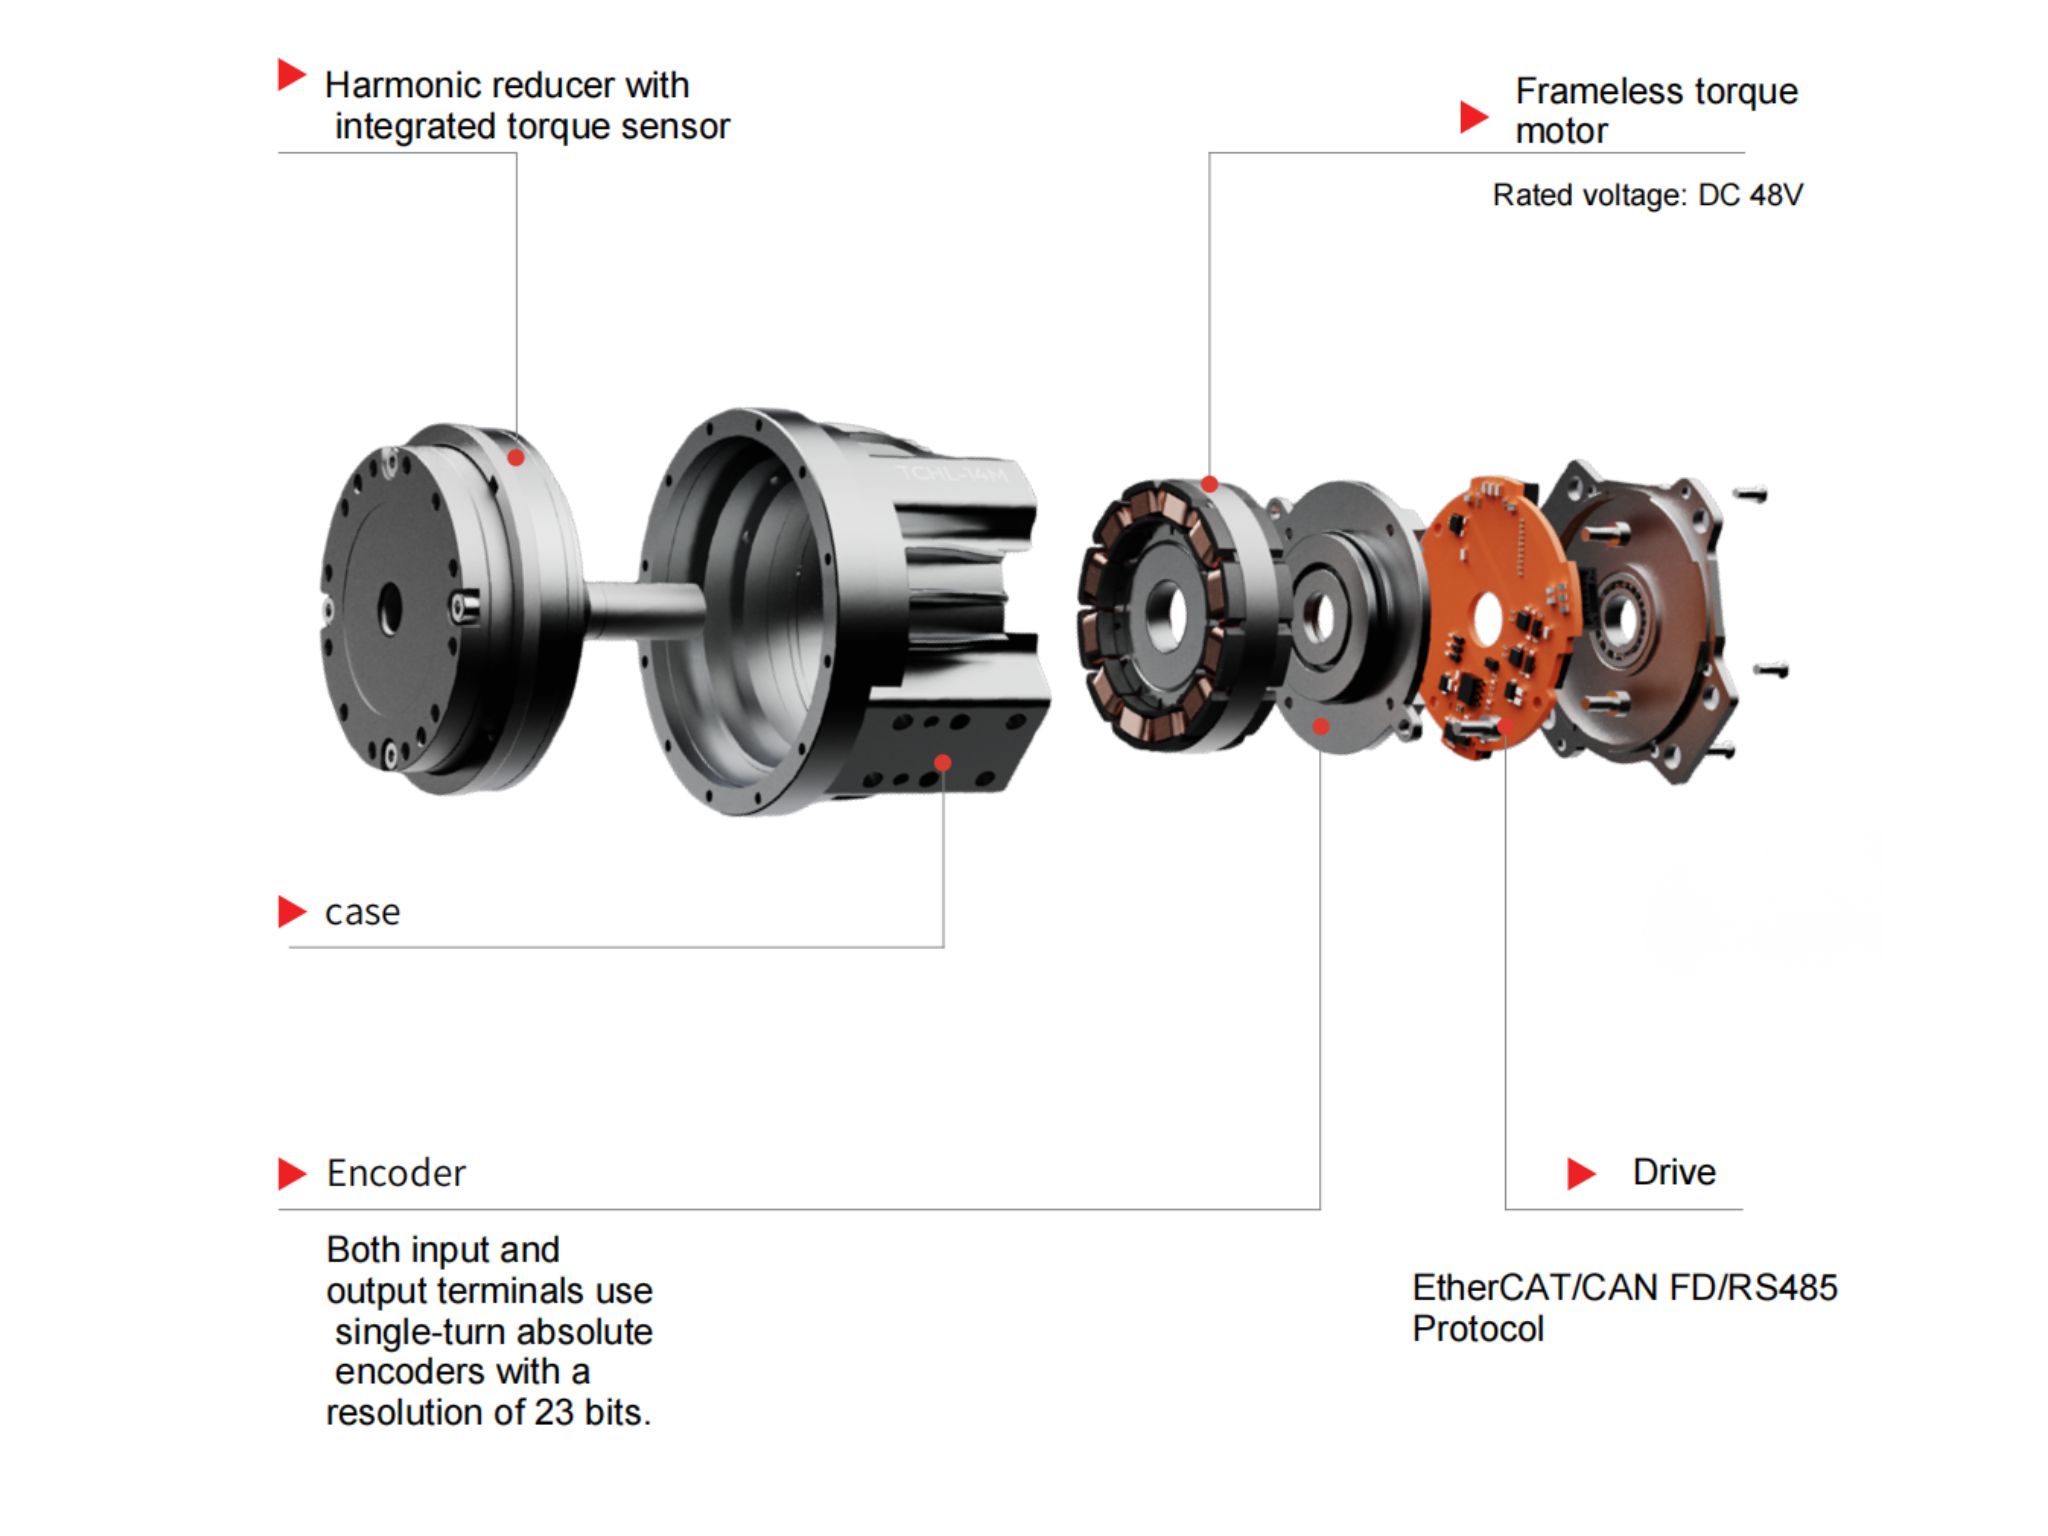
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
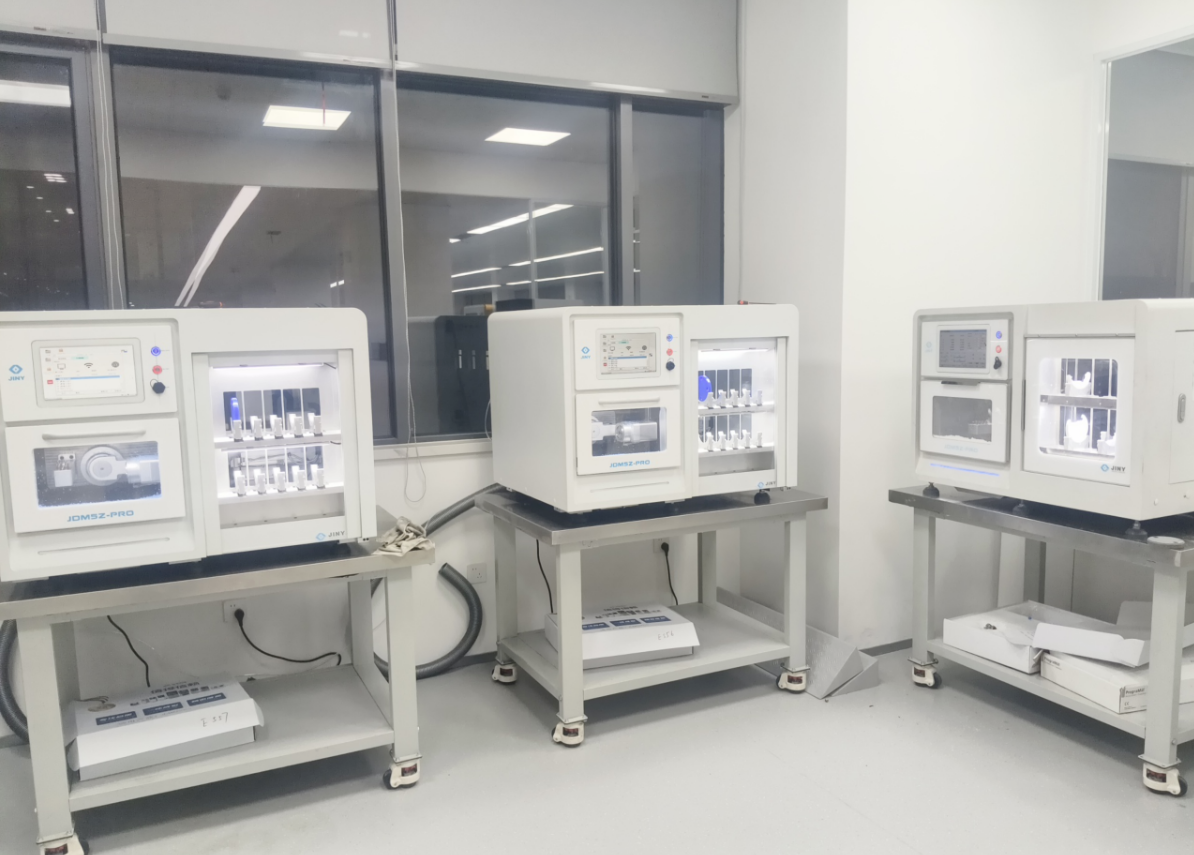
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
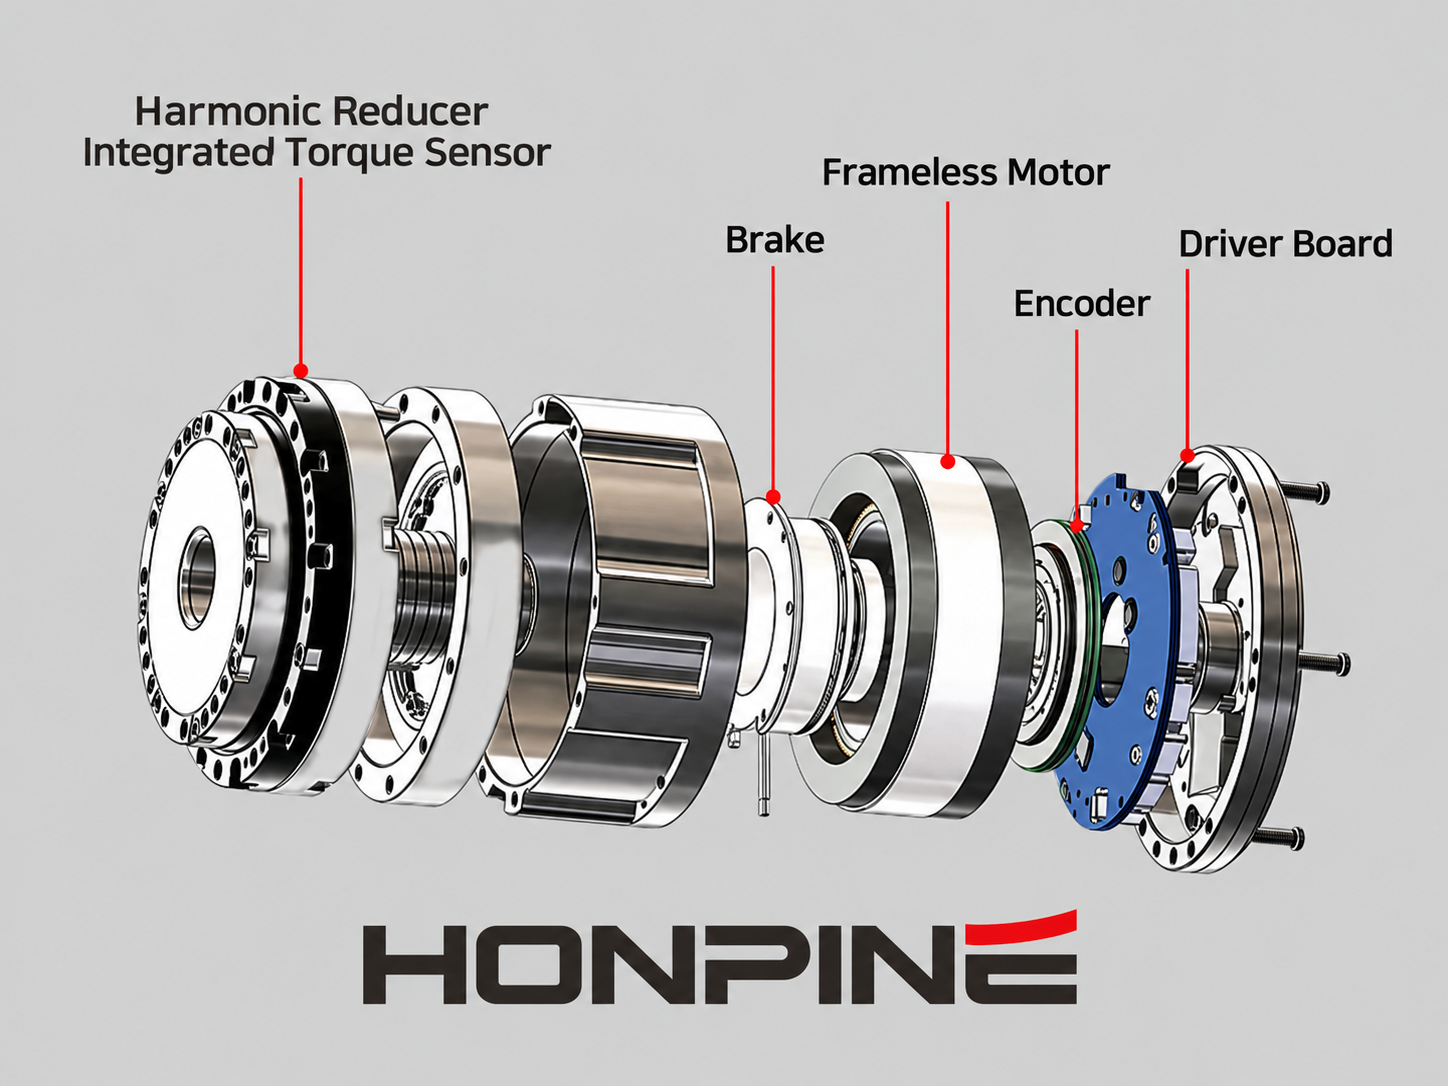
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 How to Choose Harmonic Joint Actuators for a 7-DOF Robotic Arm?I'm Theodore Li, Technical Director at HONPINE. Choosing harmonic joint actuators for a 7-DOF robotic arm starts with the torque, weight, and installation needs of each joint. This guide uses a TCHL 20 shoulder and TCHL 14 wrist configuration as an example, then explores torque sensing, compliant control, and HAG Series considerations for demanding robotic applications.
 AGV Suspension: Should You Choose a Balance Beam or a Spring-Loaded Steering Drive Unit?Choosing an AGV suspension system starts with the vehicle’s load range and floor conditions. Balance beams and spring-loaded steering drive units offer different approaches to maintaining wheel contact and managing wheel loads. This HONPINE guide compares both options and explains how to evaluate traction, suspension travel, installation space, and maintenance before choosing a configuration.
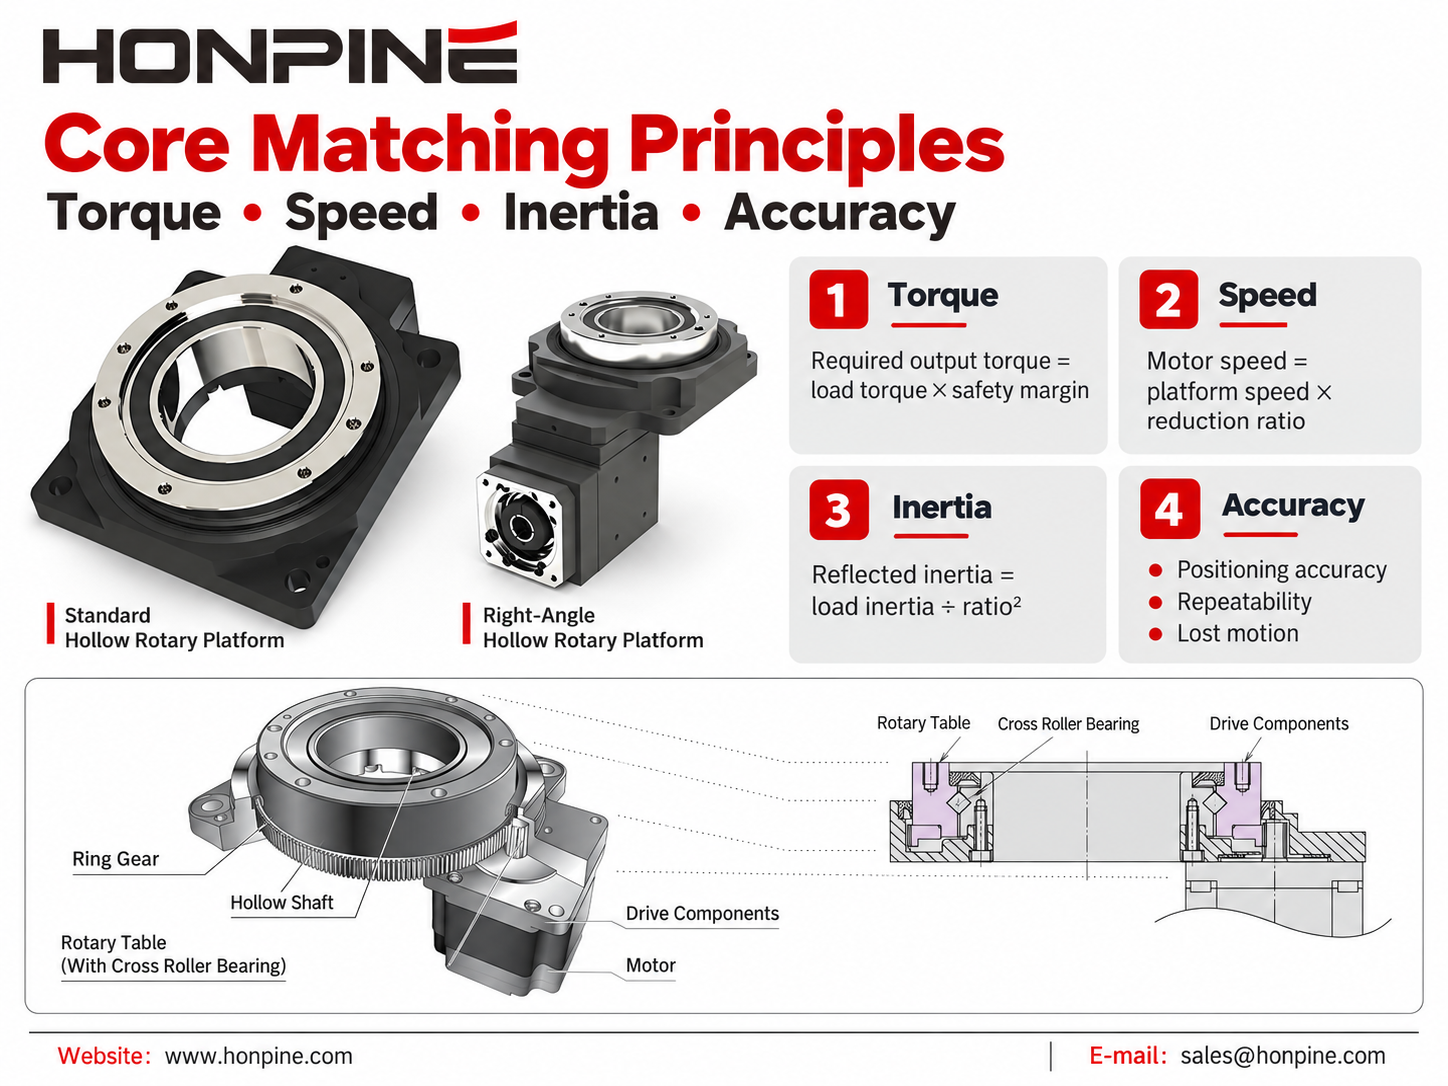
 Hollow Rotary Platform Motor Matching: A Complete GuideSelecting the right motor for a hollow rotary platform is essential for achieving precise positioning, stable operation, and efficient automation. This guide explains how to match servo motors, stepper motors, and brushless DC motors with hollow rotary platforms based on torque, speed, inertia, accuracy, and installation requirements. Explore practical motor selection guidelines, typical application combinations, and space-saving mounting solutions to find the right configuration for your automation project.
 Can Robots Feel Touch? HONPINE HAG Force-Controlled Harmonic Robot Joint MotorsCan robots respond to a gentle touch? The HONPINE HAG robot joint motor with torque sensor combines a harmonic reducer, integrated torque sensing, and closed-loop control to detect external forces and support smooth, compliant motion. In this article, HONPINE founder Allen Li demonstrates the module's response to light contact and hand-guided movement, explains its key force-control technologies, and shares the vision behind joint modules designed for practical industrial robotics.
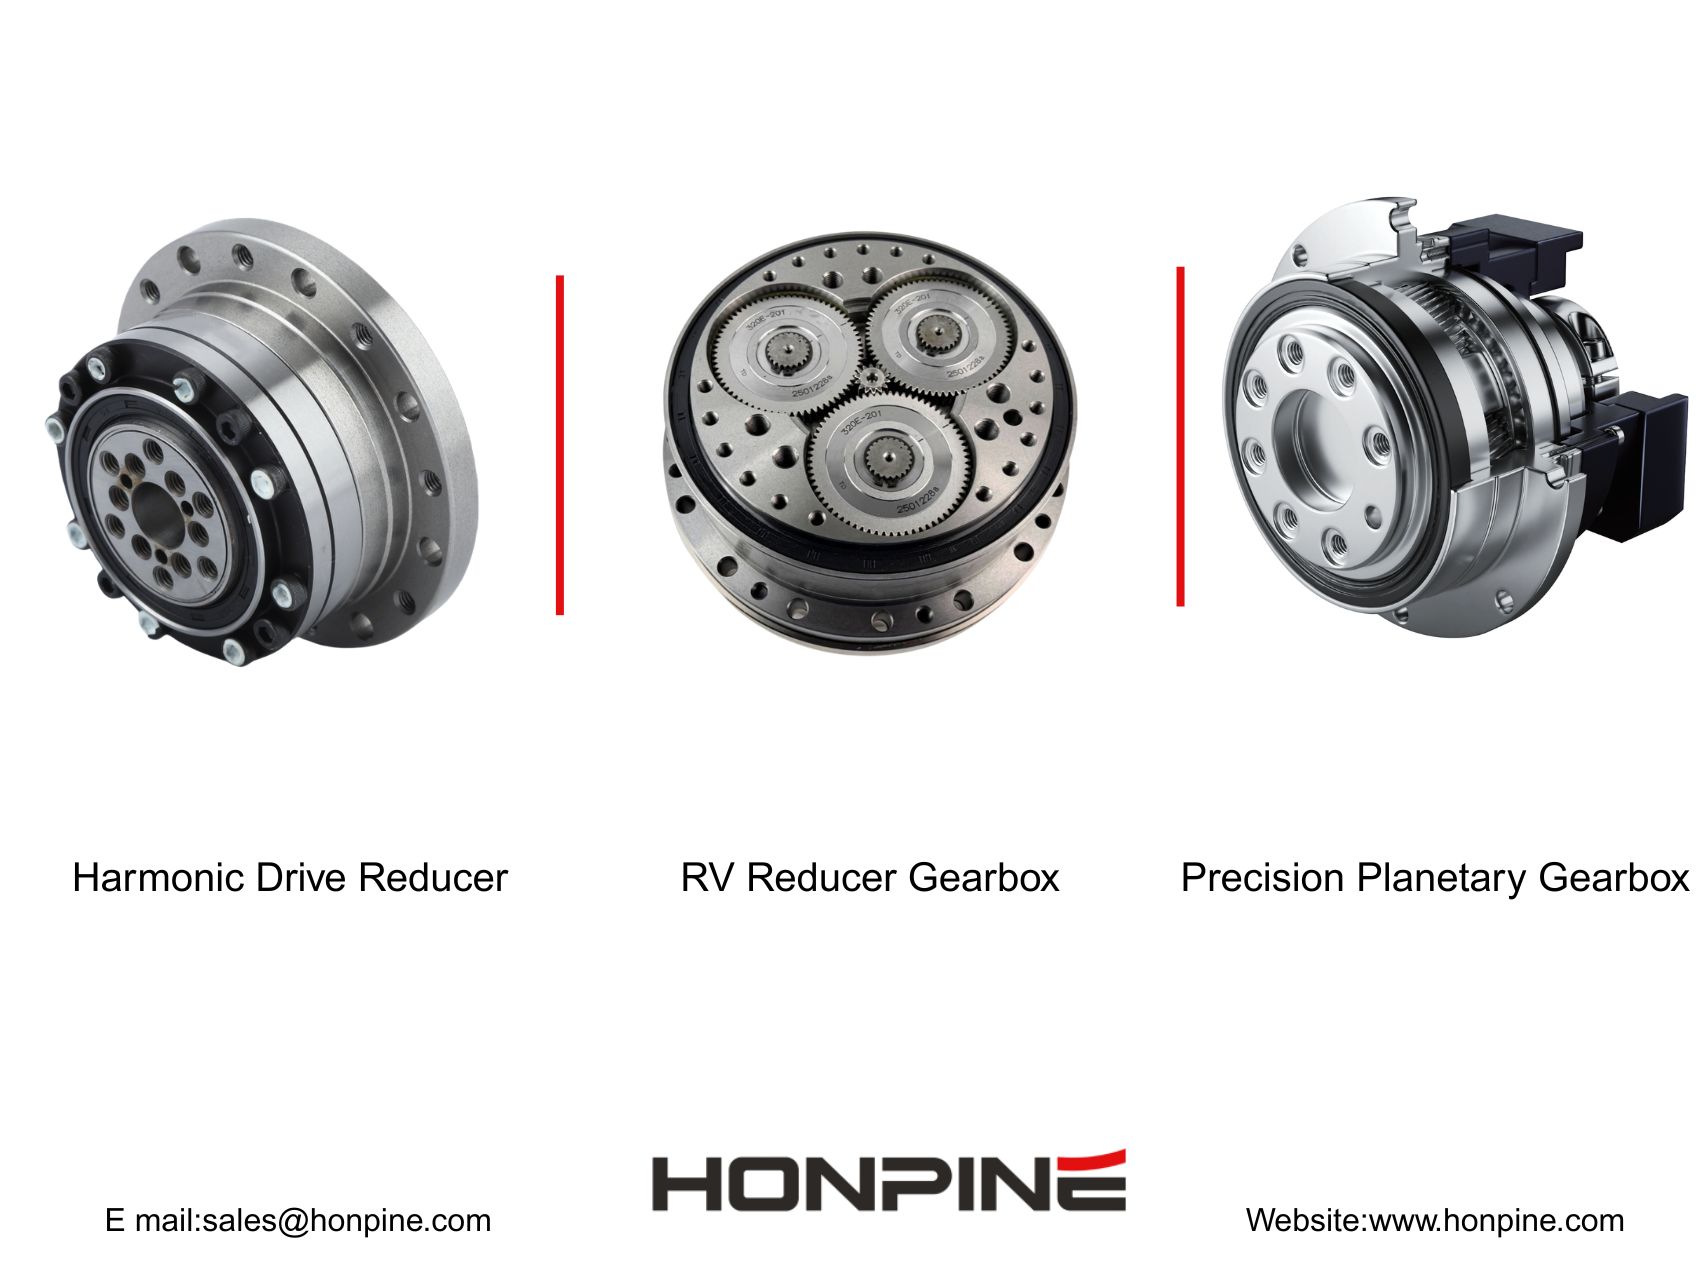
 Does a Higher Gearbox Ratio Mean More Torque? Planetary, Harmonic, and RV Gearboxes ExplainedDoes a higher gearbox ratio mean more torque? This engineering guide explains the relationship between gearbox ratio, output torque, and output speed, and compares planetary gearboxes, harmonic gearboxes, and RV gearboxes. Learn why reduction ratio alone cannot determine gearbox torque capacity, efficiency, dynamic response, precision, or service life, and what engineers should consider when selecting a gearbox for robotics, CNC machines, servo systems, and industrial motion control.
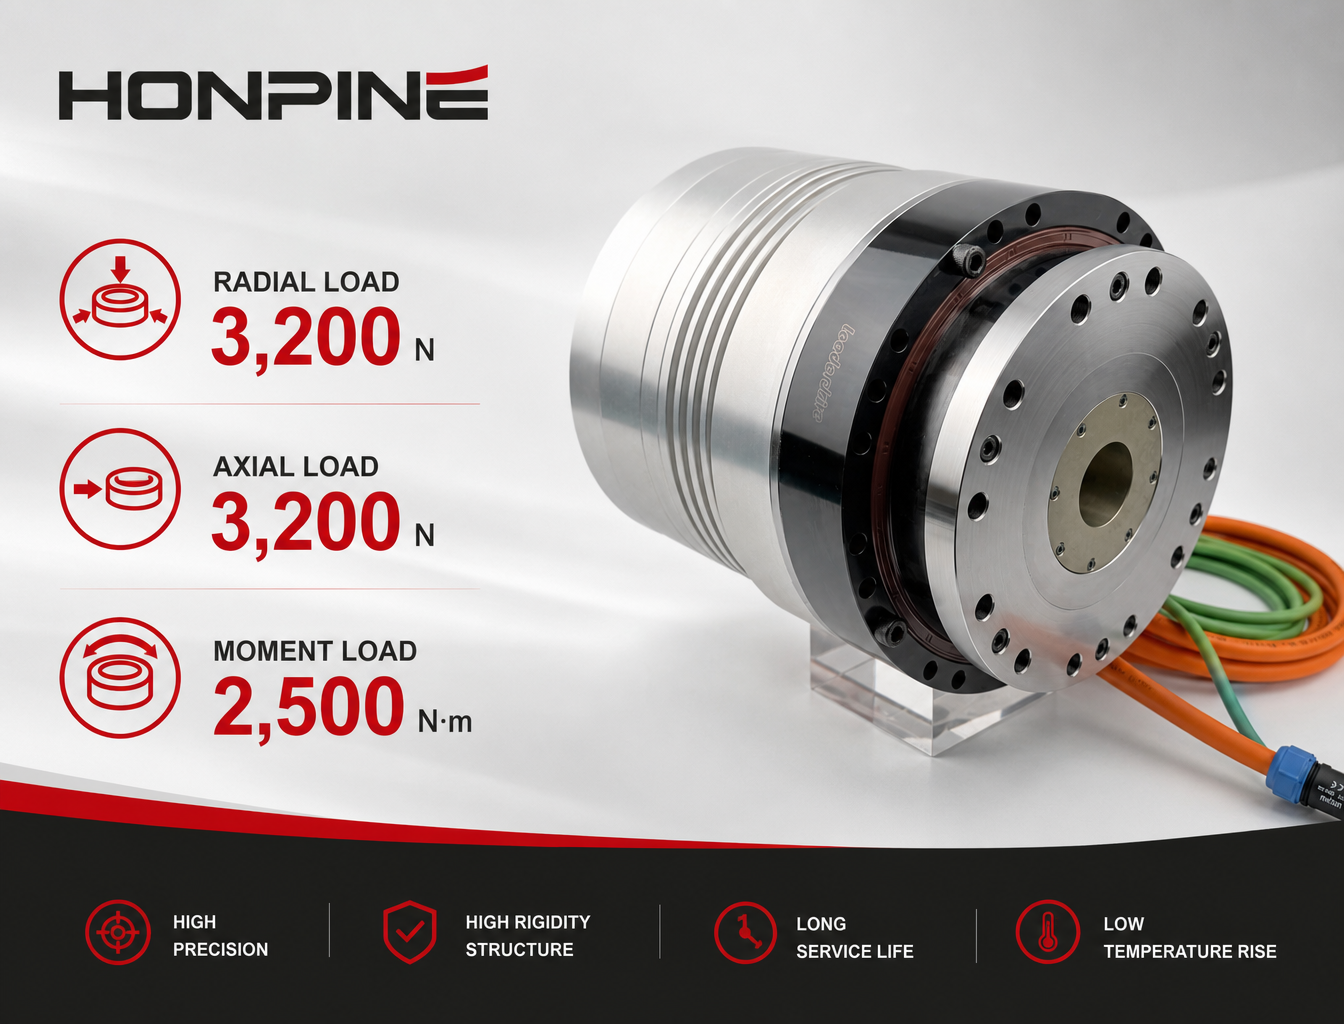
 High-Precision Hollow Harmonic Rotary Actuator for CNC Machines and Heavy-Duty Rotary AxesHONPINE 58 Series Hollow Harmonic Rotary Actuator is designed for CNC rotary tables, precision rotary axes, laser processing equipment, and heavy-duty rotary positioning applications. With a 50 mm hollow bore, up to 2,722 N·m peak torque, integrated crossed roller bearing, multi-turn absolute encoder options, positioning accuracy below 30 arcsec, and repeat positioning accuracy below 5 arcsec, it combines high torque capacity with precision rotary motion and flexible mechanical integration.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 How to Choose Harmonic Joint Actuators for a 7-DOF Robotic Arm?I'm Theodore Li, Technical Director at HONPINE. Choosing harmonic joint actuators for a 7-DOF robotic arm starts with the torque, weight, and installation needs of each joint. This guide uses a TCHL 20 shoulder and TCHL 14 wrist configuration as an example, then explores torque sensing, compliant control, and HAG Series considerations for demanding robotic applications.
 AGV Suspension: Should You Choose a Balance Beam or a Spring-Loaded Steering Drive Unit?Choosing an AGV suspension system starts with the vehicle’s load range and floor conditions. Balance beams and spring-loaded steering drive units offer different approaches to maintaining wheel contact and managing wheel loads. This HONPINE guide compares both options and explains how to evaluate traction, suspension travel, installation space, and maintenance before choosing a configuration.
 Hollow Rotary Platform Motor Matching: A Complete GuideSelecting the right motor for a hollow rotary platform is essential for achieving precise positioning, stable operation, and efficient automation. This guide explains how to match servo motors, stepper motors, and brushless DC motors with hollow rotary platforms based on torque, speed, inertia, accuracy, and installation requirements. Explore practical motor selection guidelines, typical application combinations, and space-saving mounting solutions to find the right configuration for your automation project.
 Can Robots Feel Touch? HONPINE HAG Force-Controlled Harmonic Robot Joint MotorsCan robots respond to a gentle touch? The HONPINE HAG robot joint motor with torque sensor combines a harmonic reducer, integrated torque sensing, and closed-loop control to detect external forces and support smooth, compliant motion. In this article, HONPINE founder Allen Li demonstrates the module's response to light contact and hand-guided movement, explains its key force-control technologies, and shares the vision behind joint modules designed for practical industrial robotics.
 Does a Higher Gearbox Ratio Mean More Torque? Planetary, Harmonic, and RV Gearboxes ExplainedDoes a higher gearbox ratio mean more torque? This engineering guide explains the relationship between gearbox ratio, output torque, and output speed, and compares planetary gearboxes, harmonic gearboxes, and RV gearboxes. Learn why reduction ratio alone cannot determine gearbox torque capacity, efficiency, dynamic response, precision, or service life, and what engineers should consider when selecting a gearbox for robotics, CNC machines, servo systems, and industrial motion control.
 High-Precision Hollow Harmonic Rotary Actuator for CNC Machines and Heavy-Duty Rotary AxesHONPINE 58 Series Hollow Harmonic Rotary Actuator is designed for CNC rotary tables, precision rotary axes, laser processing equipment, and heavy-duty rotary positioning applications. With a 50 mm hollow bore, up to 2,722 N·m peak torque, integrated crossed roller bearing, multi-turn absolute encoder options, positioning accuracy below 30 arcsec, and repeat positioning accuracy below 5 arcsec, it combines high torque capacity with precision rotary motion and flexible mechanical integration.
 How Does the HONPINE JRM Planetary Robot Joint Module Address Temperature Rise in Continuous Operation?HONPINE JRM planetary robot joint modules are designed for long-duration and high-load robotic operation. This article examines how motor electromagnetic optimization, high-efficiency planetary transmission, GaN-based drive technology, and system-level low-loss design help control temperature rise. Using the C6345 planetary robot joint module as a test example, HONPINE also presents full-load thermal validation under continuous operation, including motor efficiency up to 92%, planetary gearbox efficiency up to 97%, and a final equilibrium temperature of 61.42°C at a 25°C ambient temperature.
 Direct Drive Motor Sizing: A Complete Guide to Torque Calculation and SelectionSelecting a direct drive motor for a precision rotary system requires more than matching motor torque to the equipment weight. Engineers need to evaluate gravity torque, inertial torque, wind torque, friction, rotational inertia, speed, acceleration, duty cycle, and positioning requirements. In this guide, Theodore Li, Technical Director at HONPINE, explains a practical approach to direct drive motor sizing and torque calculation using an azimuth and elevation turntable as an engineering example. The article covers continuous and peak torque calculation, motor selection criteria, and the application of frameless direct drive motors in integrated rotary systems.
 How Integrated Robot Joint Modules Are Reshaping Robot Wiring and Control Architecture?Integrated robot joint modules are changing how robots are designed by combining the motor, reducer, drive, encoder, and sensing components into a compact motion unit. Compared with traditional distributed architectures, this integrated approach can reduce cable complexity, simplify power and communication connections, and support more compact robot structures. As humanoid robots demand higher levels of motion coordination, response speed, precision, and integration, robot joint modules are becoming an increasingly important interface between intelligent control systems and physical movement. This article explains how integrated robot joint modules reshape robot wiring and control architecture, using the HONPINE TCHL harmonic drive robot joint module as an example.