How Does the HONPINE JRM Planetary Robot Joint Module Address Temperature Rise in Continuous Operation?
As robots are increasingly deployed in smart factories, automated logistics, unmanned inspection, and specialized operations, 24/7 continuous operation is becoming a common requirement. Expectations for robots are also evolving from simply completing basic movements to maintaining stable and reliable performance over extended operating periods.
As a core motion component, the thermal performance of a robot joint module directly affects the operating stability of the entire robotic system. Increasing demands for long-duration and high-load operation therefore place higher requirements on joint temperature control.
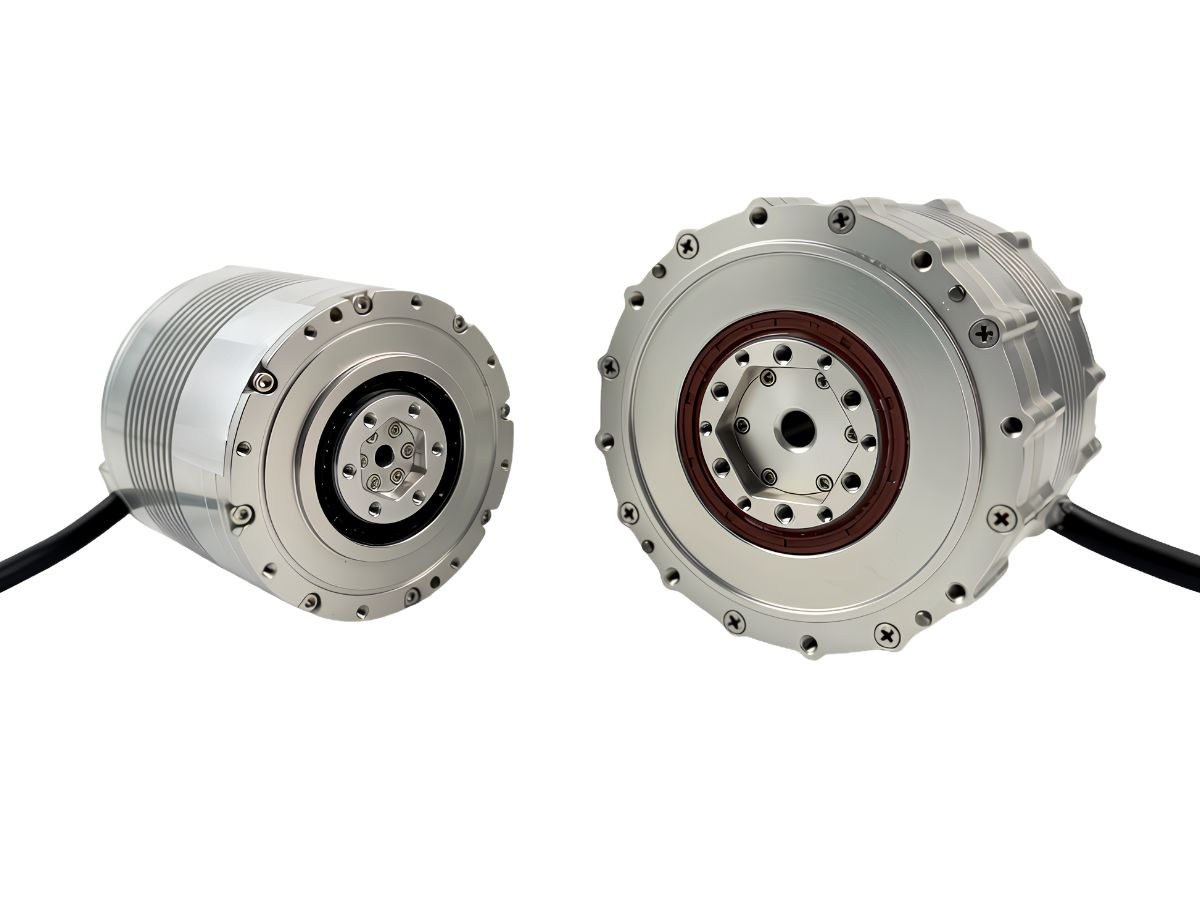
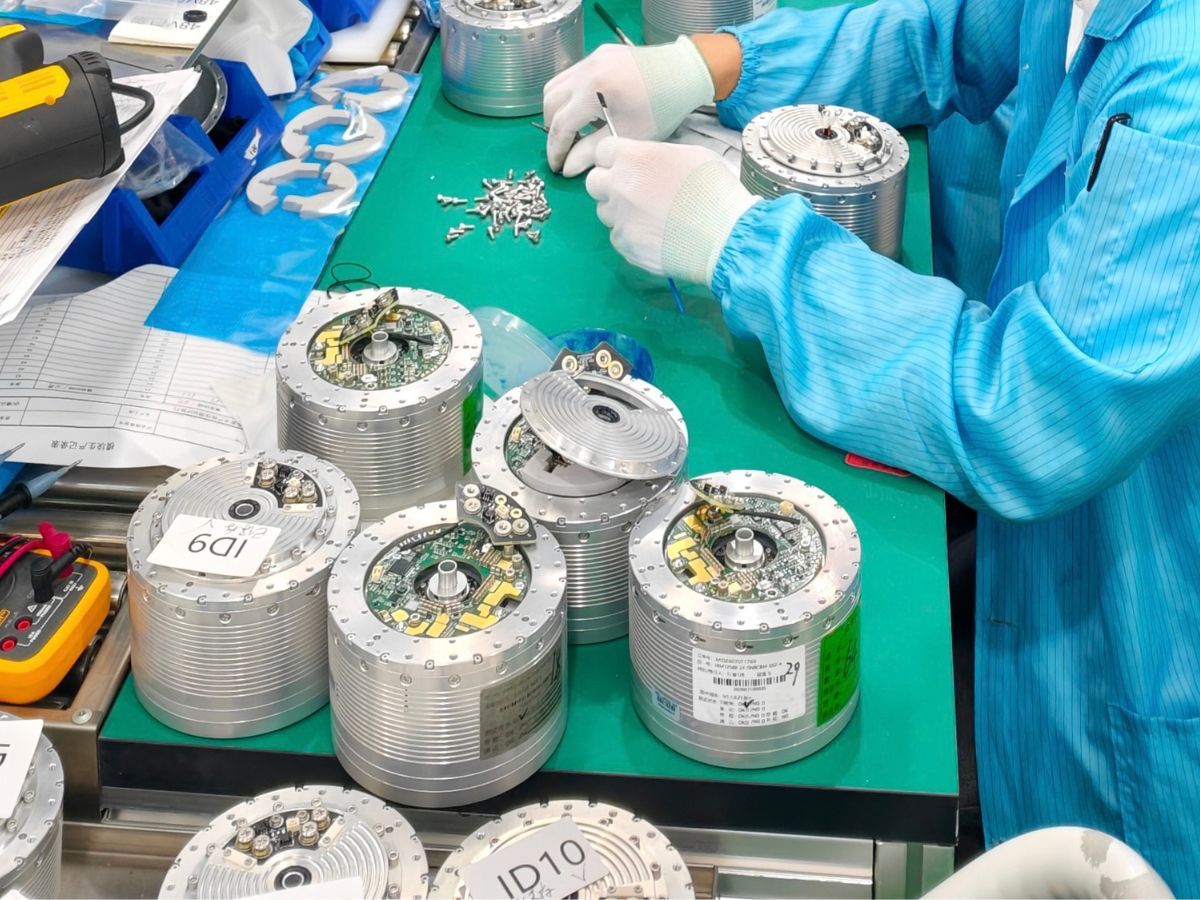
To address the common challenge of temperature rise in robot joints, HONPINE focuses on the underlying design of the joint module rather than relying primarily on external cooling as a corrective measure. With high energy conversion efficiency and low-loss operation as key design objectives, HONPINE develops integrated robot joint modules (JRM Planetary Joint Module) designed for low temperature rise, high reliability, and scalable production, providing core motion components for robotic systems operating under demanding conditions.
During long-duration, high-load operation, losses from the motor, transmission, and drive unit are major sources of heat accumulation within a robot joint. The compact structure of a joint module also limits available heat dissipation space, making thermal management particularly challenging during continuous operation.
To address this challenge, HONPINE has developed a self-developed thermal management approach based on reducing losses throughout the joint module and controlling heat generation at its sources. Starting from the underlying design of the module, the approach aims to reduce heat generation and improve thermal stability during continuous operation.
1. Design Strategy: Control Temperature Rise at the Source
HONPINE focuses on optimizing the primary heat-generating components of the robot joint module rather than relying solely on downstream cooling measures.
Through efficiency improvements across the motor, planetary gearbox, and drive unit, HONPINE reduces electromagnetic losses, mechanical friction losses, and power-device switching losses during operation. By reducing heat generation at the source, the joint module can maintain lower heat accumulation within its compact integrated structure.
This system-level low-loss design is intended to support stable thermal performance under long-duration continuous operation.
2. Motor Optimization: Multi-Dimensional Electromagnetic Design
The motor is one of the primary heat-generating components in a robot joint module. Copper loss and iron loss have a direct impact on the basic temperature-rise characteristics of the module. HONPINE therefore optimizes the motor from multiple aspects, including magnetic circuit design, material selection, and winding processes, to improve electromagnetic energy conversion efficiency.
Electromagnetic Design
HONPINE optimizes the pole-slot combination to improve the winding factor while refining the magnetic circuit and air-gap structure.
For low-speed operation, cogging torque is controlled to within 1% of rated torque, helping maintain smooth motion and stable low-speed operation.
For high-speed operation, the back-EMF harmonic distortion rate is controlled to within 1%, helping reduce iron losses and improve efficiency during high-speed operation.
High-Performance Materials
The stator and rotor use 0.2 mm high-grade non-oriented electrical steel, helping reduce eddy-current losses and improve magnetic saturation characteristics.
The motor also uses UH-series high-grade high-temperature-resistant permanent magnets, providing high residual flux density and high coercivity to reduce the risk of demagnetization under high-load operating conditions.
Key materials, including the electromagnetic wire, insulation components, and bonding adhesive, are selected in high-temperature specifications. The core components can withstand temperatures of up to 180°C, supporting long-duration continuous operation.
Winding Process
The motor uses an automated multi-slot continuous winding process, increasing the slot fill factor to 80%.
Under the same torque output conditions, a higher slot fill factor can help reduce current-related heat generation. The winding process also reduces the number of solder joints, improving overall operational reliability.
With these combined optimizations, the motor achieves an overall efficiency of up to 92%, helping reduce heat generation at one of the primary heat sources within the joint module.
3. Transmission and Drive Efficiency: Reducing Losses Across the Powertrain
In addition to motor losses, mechanical friction in the planetary gearbox and switching losses in the drive unit can also affect the thermal performance of a robot joint module during continuous operation.
Planetary Transmission Efficiency
On the transmission side, HONPINE optimizes the structure and matching precision of the planetary gearbox.
The efficiency of the single-stage planetary gearbox can reach up to 97%, while the efficiency of the two-stage planetary gearbox remains around 95% under the specified operating conditions.
Higher transmission efficiency helps reduce mechanical losses and the associated heat generated by gear meshing and friction.
Drive Efficiency
On the drive side, the joint module uses third-generation gallium nitride (GaN) power devices.
Compared with conventional power devices, GaN devices can significantly reduce conduction and switching losses. The drive unit achieves an overall operating efficiency of more than 95%, helping reduce heat generation associated with high-frequency electrical switching.
Through coordinated optimization of the transmission and drive systems, the joint module is designed to achieve efficient operation across the entire powertrain.
4. Full-Load Validation: Temperature Rise Below 1 K After 30 Minutes
The low-loss and low-temperature-rise characteristics achieved through theoretical design must ultimately be verified under actual load conditions.
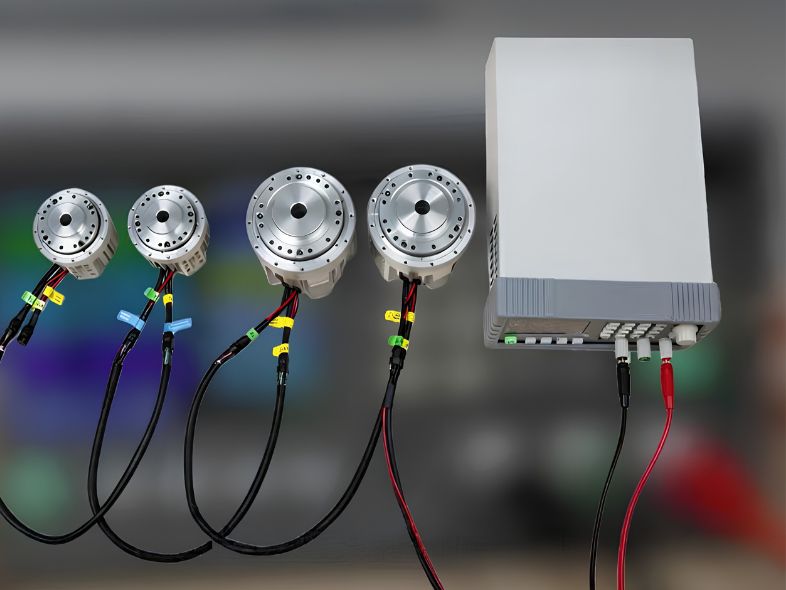
To simulate the continuous operating conditions of robots working under demanding loads, HONPINE conducted a full-load back-to-back test on the C6345 planetary robot joint module.
The C6345 module has a rated torque of 12 N·m and a rated speed of 120 rpm. A servo back-to-back test setup was used to reproduce continuous loaded operation.
After 90 minutes of continuous full-load operation, the joint module reached a stable thermal equilibrium.
Under an ambient temperature of 25°C, the temperature-rise difference after 30 minutes was below 1 K, while the final equilibrium temperature stabilized at 61.42°C.
Even under full-load operating conditions, the joint module maintained a stable thermal equilibrium, helping prevent continuous temperature escalation during prolonged operation.
5. Underlying Performance for Long-Duration Continuous Robot Operation
From multi-dimensional motor optimization and source-level reduction of electromagnetic losses to efficiency improvements across the transmission and drive systems, HONPINE approaches thermal management by reducing heat generation throughout the joint module.
The full-load test of the C6345 planetary robot joint module further demonstrates its thermal behavior under continuous operating conditions.
By combining high motor efficiency, efficient planetary transmission, high-efficiency GaN drive technology, and system-level low-loss design, HONPINE develops planetary robot joint modules designed to reduce thermal management challenges for robotic system integrators.
This approach is intended to support robots operating under long-duration, high-load, and continuous-duty conditions, while providing a stable thermal foundation for reliable robotic motion.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 How Does the HONPINE JRM Planetary Robot Joint Module Address Temperature Rise in Continuous Operation?HONPINE JRM planetary robot joint modules are designed for long-duration and high-load robotic operation. This article examines how motor electromagnetic optimization, high-efficiency planetary transmission, GaN-based drive technology, and system-level low-loss design help control temperature rise. Using the C6345 planetary robot joint module as a test example, HONPINE also presents full-load thermal validation under continuous operation, including motor efficiency up to 92%, planetary gearbox efficiency up to 97%, and a final equilibrium temperature of 61.42°C at a 25°C ambient temperature.
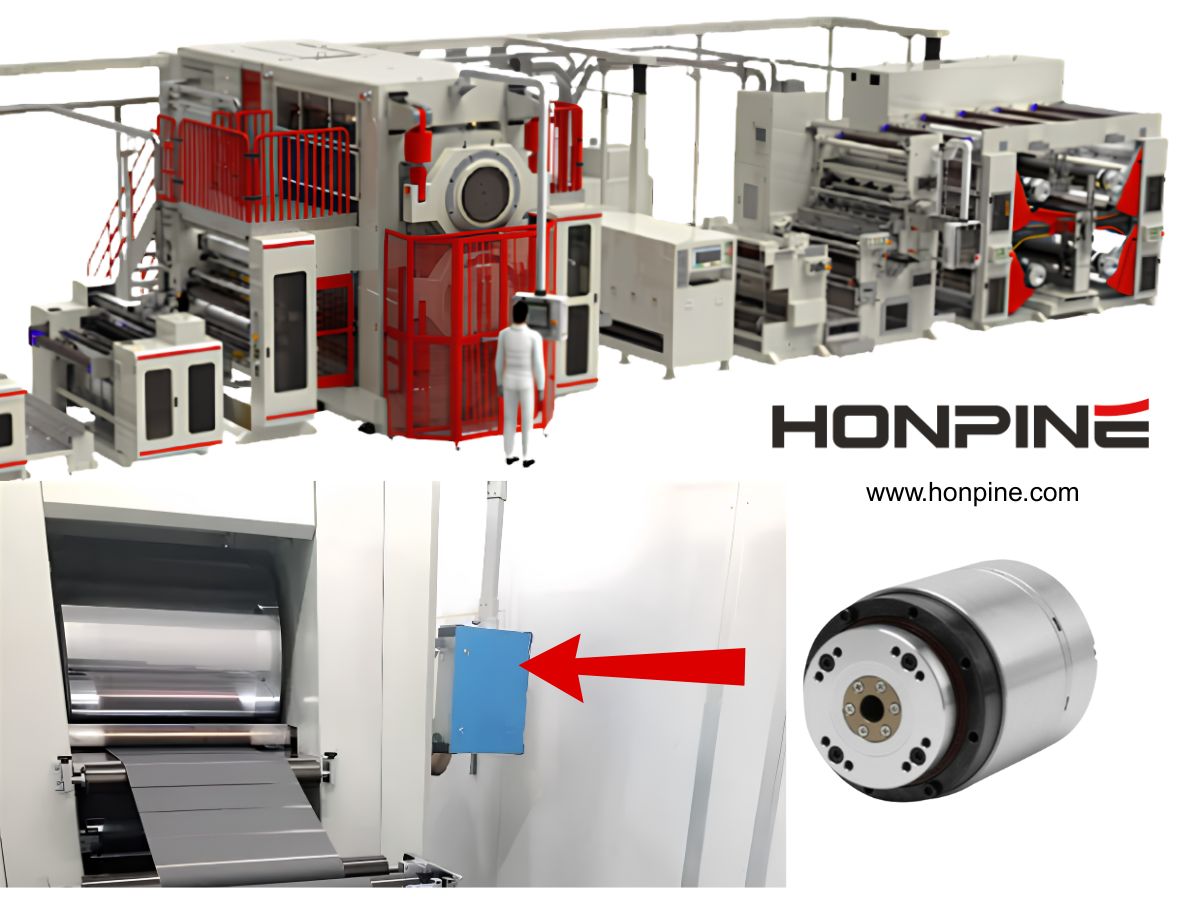
 Harmonic Rotary Actuator for Lithium Battery Roller Press EquipmentLithium battery manufacturing equipment requires higher precision, stability, and integration efficiency as production processes continue to evolve. In roller press equipment, accurate roller positioning, pressure control, and dynamic response are critical for ensuring electrode quality and consistency.
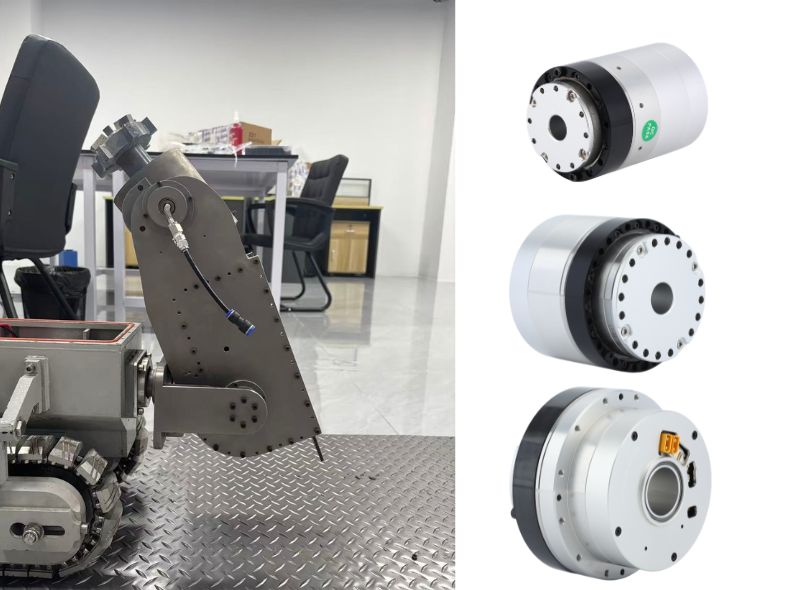
HONPINE harmonic rotary actuators provide high precision, high rigidity, fast response, and compact integration for lithium battery roller press equipment. With near-zero backlash, high torque density, and reliable motion control performance, they help improve equipment accuracy and production stability. Harmonic Robot Joint Actuators for Pipeline Robots and Other Special-Purpose EquipmentPipeline robots operate in narrow and complex environments where limited installation space, high load requirements, cable routing, and precise motion control are critical challenges. A reliable joint actuator must provide high torque output, compact dimensions, and stable performance while adapting to demanding operating conditions. Harmonic robot joint actuators integrate precision transmission, motor drive, and sensing capabilities into a compact motion unit, making them suitable for pipeline robots and other special-purpose robotic systems. This article explores the key design requirements of pipeline robots and explains how HONPINE HPJM harmonic robot joint modules help achieve compact, high-performance, and reliable robotic solutions.
 How Integrated Robot Joint Modules Are Reshaping Robot Wiring and Control Architecture?Integrated robot joint modules are changing how robots are designed by combining the motor, reducer, drive, encoder, and sensing components into a compact motion unit. Compared with traditional distributed architectures, this integrated approach can reduce cable complexity, simplify power and communication connections, and support more compact robot structures. As humanoid robots demand higher levels of motion coordination, response speed, precision, and integration, robot joint modules are becoming an increasingly important interface between intelligent control systems and physical movement. This article explains how integrated robot joint modules reshape robot wiring and control architecture, using the HONPINE TCHL harmonic drive robot joint module as an example.
 Harmonic Actuator for Lift Equipment: Precision, Torque Density and Compact Motion Control IntroductionModern lifting equipment requires more than simply moving a load vertically. Robotic lift axes, AGV and AMR lift modules, semiconductor equipment, inspection platforms, and specialized winches increasingly demand high torque density, precise positioning, low backlash, high rigidity, and compact motion control. A harmonic actuator integrates a harmonic drive with a motor and, depending on the configuration, encoders, brakes, servo drives, and communication interfaces into a compact motion module. This article explores how harmonic actuators can be applied to different lifting systems and why their combination of precision, torque density, rigidity, and integration makes them suitable for automated lifting and positioning applications.
 Force-Controlled Harmonic Joint Modules: A Key Solution for Robot CommercializationAs robots move from precise positioning toward physical interaction, joint-level torque feedback is becoming increasingly important. A force-controlled robot joint module allows the robot to sense changes in output torque and respond more appropriately to external loads, supporting compliant motion, contact detection, and force-controlled applications. HONPINE HAG and HAU harmonic joint modules integrate torque sensing directly into the joint, enabling torque closed-loop control, 360° continuous output rotation, less than 1% torque control accuracy, and a 50 Hz torque bandwidth. This integrated design also maintains consistent dimensions between force-controlled and non-force-controlled configurations, providing a flexible joint platform for robot manufacturers.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 How Does the HONPINE JRM Planetary Robot Joint Module Address Temperature Rise in Continuous Operation?HONPINE JRM planetary robot joint modules are designed for long-duration and high-load robotic operation. This article examines how motor electromagnetic optimization, high-efficiency planetary transmission, GaN-based drive technology, and system-level low-loss design help control temperature rise. Using the C6345 planetary robot joint module as a test example, HONPINE also presents full-load thermal validation under continuous operation, including motor efficiency up to 92%, planetary gearbox efficiency up to 97%, and a final equilibrium temperature of 61.42°C at a 25°C ambient temperature.
 How Integrated Robot Joint Modules Are Reshaping Robot Wiring and Control Architecture?Integrated robot joint modules are changing how robots are designed by combining the motor, reducer, drive, encoder, and sensing components into a compact motion unit. Compared with traditional distributed architectures, this integrated approach can reduce cable complexity, simplify power and communication connections, and support more compact robot structures. As humanoid robots demand higher levels of motion coordination, response speed, precision, and integration, robot joint modules are becoming an increasingly important interface between intelligent control systems and physical movement. This article explains how integrated robot joint modules reshape robot wiring and control architecture, using the HONPINE TCHL harmonic drive robot joint module as an example.
 Force-Controlled Harmonic Joint Modules: A Key Solution for Robot CommercializationAs robots move from precise positioning toward physical interaction, joint-level torque feedback is becoming increasingly important. A force-controlled robot joint module allows the robot to sense changes in output torque and respond more appropriately to external loads, supporting compliant motion, contact detection, and force-controlled applications. HONPINE HAG and HAU harmonic joint modules integrate torque sensing directly into the joint, enabling torque closed-loop control, 360° continuous output rotation, less than 1% torque control accuracy, and a 50 Hz torque bandwidth. This integrated design also maintains consistent dimensions between force-controlled and non-force-controlled configurations, providing a flexible joint platform for robot manufacturers.
 6 Key Advantages of the HONPINE JRM Planetary Joint ModuleHigh-performance quadruped robots require joint modules that can respond quickly, maintain precise positioning, withstand repeated impacts, and deliver stable torque under demanding operating conditions. The HONPINE JRM planetary joint module combines high positioning accuracy, low backlash, fast three-loop response, high static rigidity, strong overload capability, and a wide operating temperature range. With clearly defined continuous and overload operating limits, the JRM is designed to balance dynamic performance with long-term reliability. This article introduces six key advantages of the HONPINE JRM planetary joint module and explains why it is suitable for industrial inspection quadrupeds, specialized inspection robots, explosion-proof quadruped robots, and other high-performance robotic platforms.
 Robot Joint Module Solutions for Humanoid Robot Arms and LegsHumanoid robots require different joint characteristics across the shoulder, elbow, wrist, hip, knee, and ankle. Smaller joints prioritize low weight and fast response, while larger joints require higher torque density, load capacity, and reliability. A suitable robot joint module should therefore be matched to the specific torque, weight, range of motion, and control requirements of each joint. In this article, HONPINE uses the HPJM harmonic joint module series as an example to present a joint configuration solution for humanoid robot upper and lower limbs, covering torque requirements from small wrist and finger joints to high-load hip joints.
 Why Does an RV Reducer Need Profile Modification? How to Further Reduce Backlash and Transmission Error?An RV Reducer is designed to deliver high torque, high stiffness, and precise motion for demanding applications such as robotic joints, industrial rotary tables, and precision machinery. However, achieving low backlash and stable transmission accuracy requires more than high-precision machining. Cycloidal profile modification must also account for manufacturing tolerances, assembly errors, load-induced deformation, thermal expansion, and lubrication conditions. In this article, we examine why RV reducers require profile modification, how different modification methods affect meshing, and how engineers can further control backlash and transmission error through profile design, error budgeting, structural analysis, precision manufacturing, and validation testing.
 How to Choose a Hollow Rotary Platform: A Complete Selection Guide?A hollow rotary platform is widely used in precision automation where rotary positioning, compact integration, and cable routing through the rotation axis are required. However, choosing the right platform involves more than comparing rated torque or maximum speed. Load, eccentricity, overturning moment, inertia, positioning accuracy, hollow bore, acceleration, duty cycle, and installation conditions all affect the actual performance of the rotary system. This guide explains the key parameters engineers should consider when selecting a hollow rotary platform for CNC indexing, wafer handling, vision inspection, laser processing, dispensing, and other precision rotary applications.
 Hollow Robot Joint Module: Why Cable Routing Matters in Robotic Joints?A hollow robot joint module provides an internal passage for power cables, signal lines, pneumatic tubes, and other end-effector connections. Compared with external cable routing, a hollow joint module can help reduce cable exposure, improve system integration, and create a cleaner motion path for robotic arms. This article explains why internal cable routing matters in robotic joints and what to consider when selecting a hollow joint module for robotic applications.
 Precision Reducers for Industrial Robots: From Conventional Transmission to Self-Compensating Backlash TechnologyHello everyone, I’m Theodore Li, Technical Director at HONPINE. Today, I would like to discuss precision reducers for industrial robots and the challenges of maintaining transmission accuracy over long-term operation. Harmonic, RV, cycloidal, and planetary transmissions each offer different combinations of precision, rigidity, torque density, and compactness, making reducer selection highly dependent on robot architecture and joint requirements. However, initial backlash is only part of the problem. As transmission components wear, changes in mechanical clearance can gradually affect positioning performance. This article examines the major precision transmission technologies used in industrial robots and introduces HONPINE’s self-compensating backlash technology, which is designed to address precision retention throughout the operating life of a transmission.