How to Select Planetary Joint Motors for Quadruped Robots?
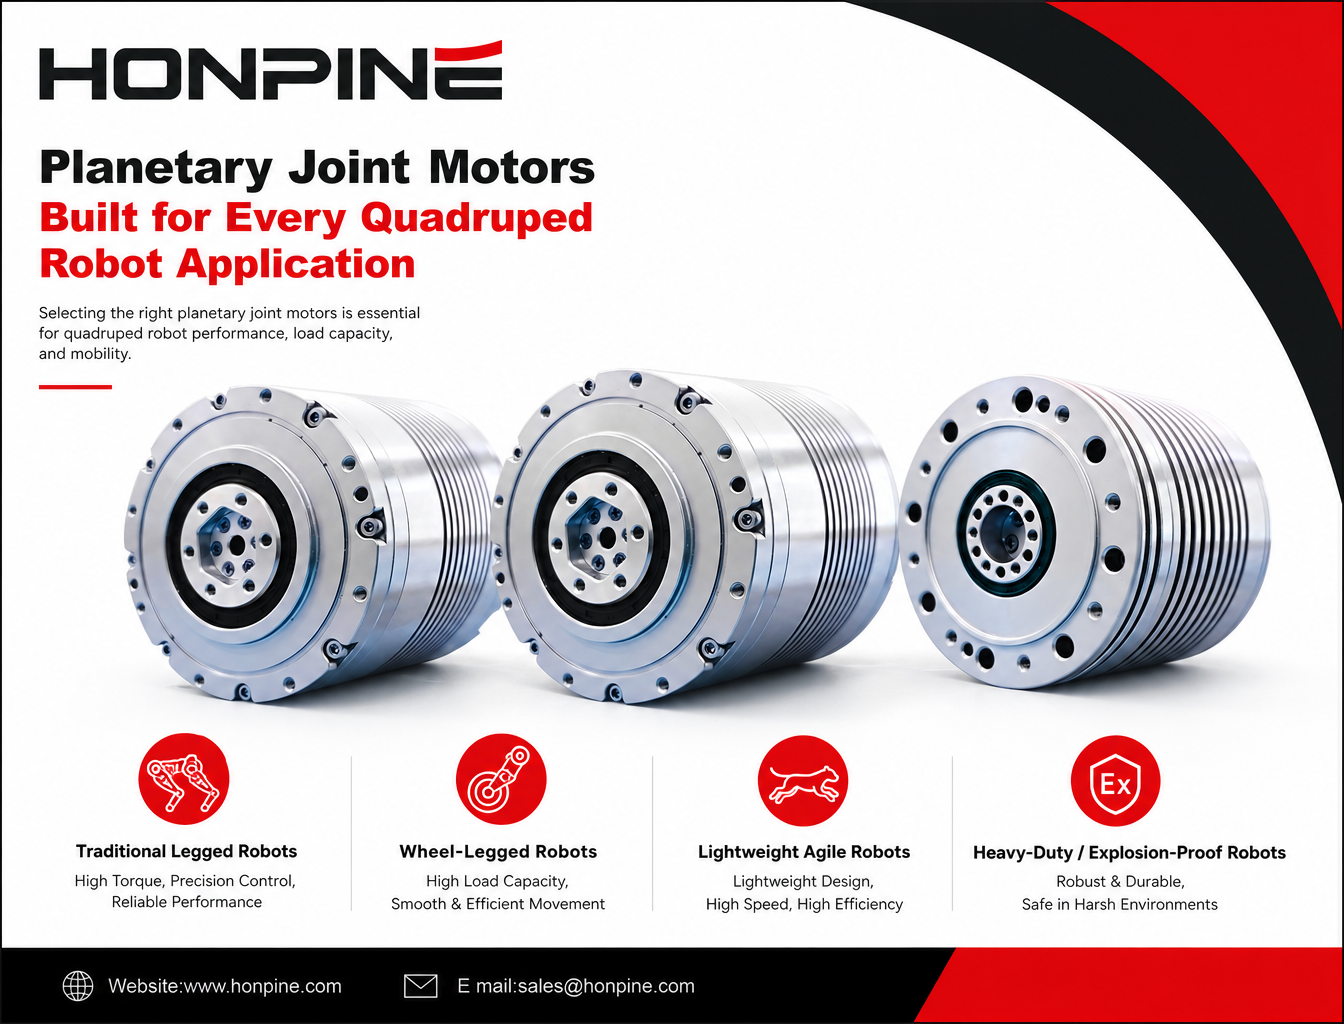
Quadruped robots generally fall into three main categories: traditional legged robots, wheel-legged robots, and heavy-duty or specialized quadruped robots. Hello everyone, I'm Theodore Li, Technical Director at HONPINE. Different types of quadruped robots have different joint requirements, so we recommend different planetary joint motor models for each application.
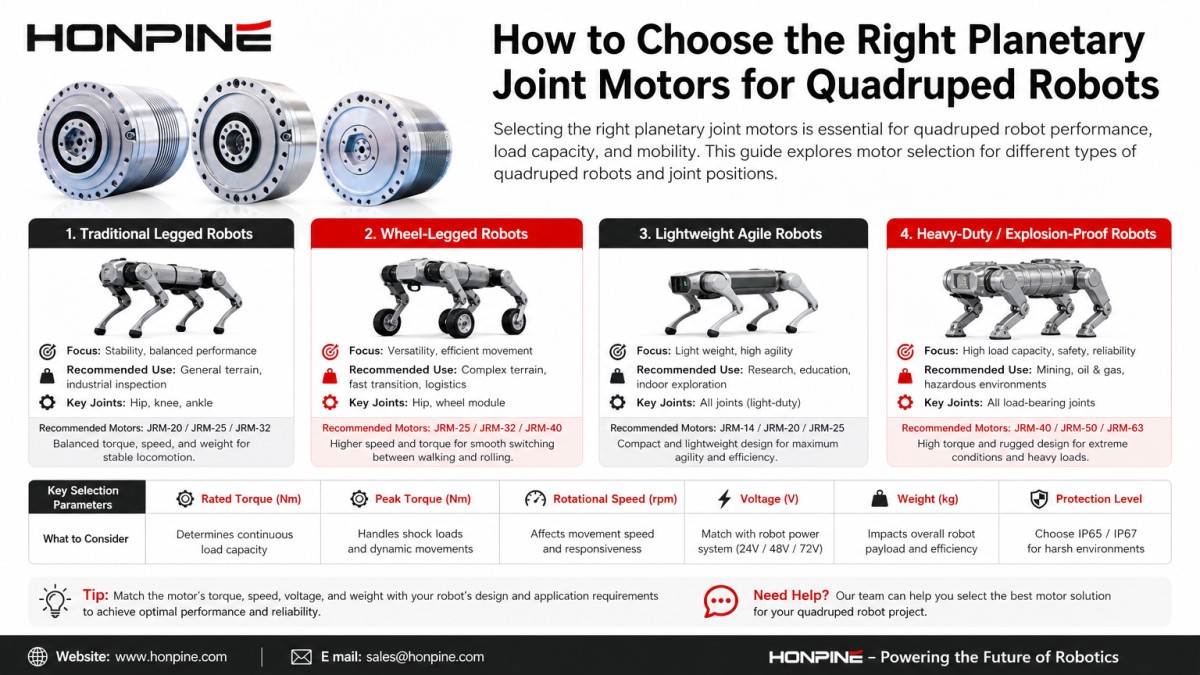
1. Traditional Medium-to-Large Legged Quadruped Robots (12 DOF: 4 Legs × 3 Joints)
Hip Abduction Joint
Requirements: Primarily responsible for moving the legs outward and inward. This joint must withstand lateral forces and typically requires a moderate torque output.
Recommended Models:
JRM-C9577-024: Rated torque of 46 N·m, peak torque of 155 N·m, 48 V.
JRM-C10483.5-20.4: 48 V version, rated torque of 42 N·m and peak torque of 200 N·m.
Both models offer a suitable size and sufficient torque to provide stable support for the robot body.
Hip Pitch Joint
Requirements: One of the main load-bearing joints in a quadruped robot. It requires high torque to lift and support the robot's body and withstand impact forces during landing.
Recommended Models:
JRM-C12585-022: Rated torque of 76 N·m, peak torque of 376 N·m, 48 V.
JRM-C150100-22: Rated torque of 160 N·m, peak torque of 600 N·m, 72 V.
These high-torque models serve as the robot's primary leg muscles and are suitable for medium-to-large quadruped robots that require substantial joint output.
Knee Joint
Requirements: Requires high rotational speed for rapid leg extension and retraction, as well as strong impact resistance, especially during running.
Recommended Models:
JRM-C9577-024: A high-speed option, 48 V.
JRM-C8567-032: Rated torque of 38 N·m, peak torque of 155 N·m, suitable for medium-sized quadruped robots.
2. Wheel-Legged Quadruped Robots
Hip and Knee Joints
The hip and knee joints can use the same models recommended for traditional legged quadruped robots, such as the JRM-C12585 and JRM-C9577 series.
Hub Motor Drive (End-Wheel Drive)
Requirements: The wheel drive requires high rotational speed for fast rolling, a compact and flat design, and a hollow structure for cable routing.
Recommended Models:
JRM-C9579.6-008: Hub motor series, 72 V, rated torque of 18 N·m, speed of 400 rpm.
JRM-C12582-008: Hub motor series, 72 V, rated torque of 32 N·m, speed of 375 rpm, peak torque of 145 N·m.
The hub motor series is naturally suited to wheel-foot configurations, enabling quadruped robots to switch between legged walking and wheeled movement.
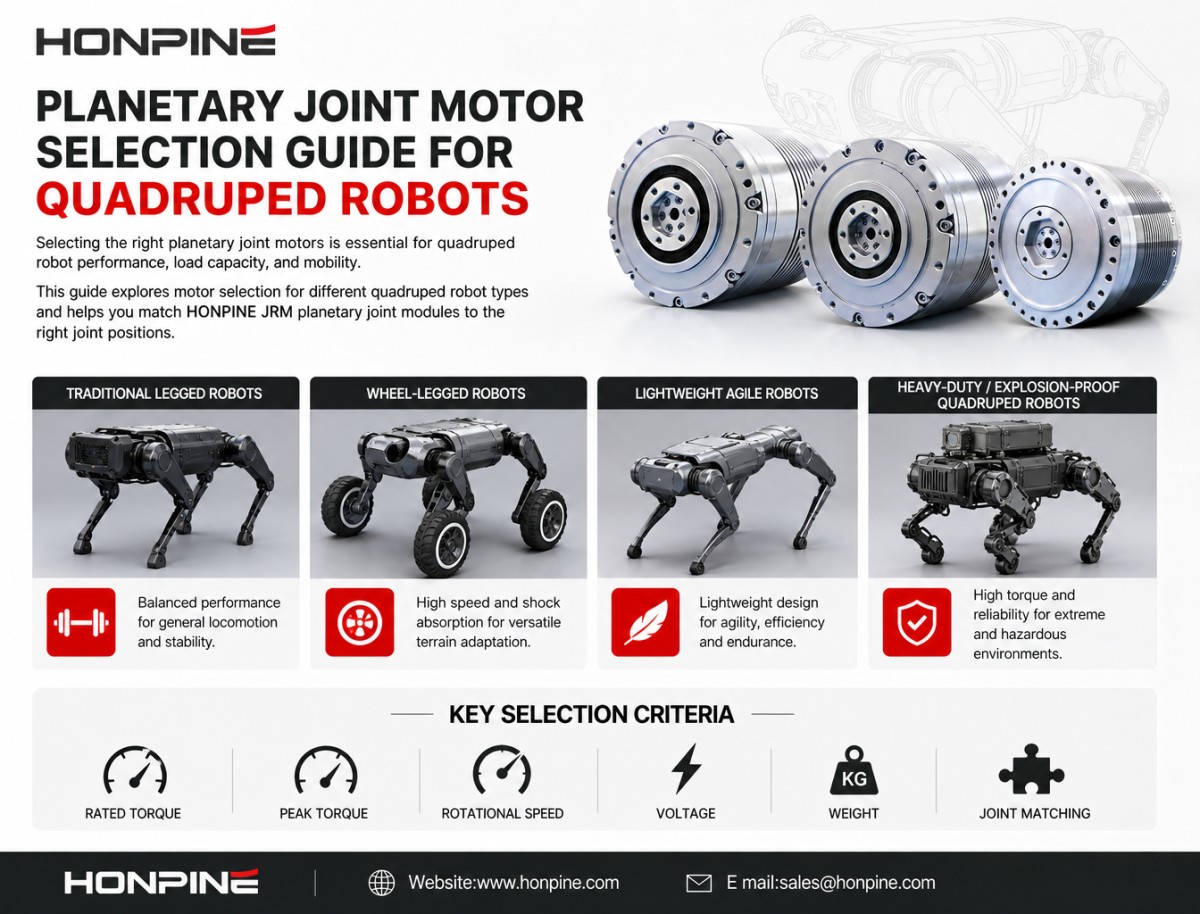
3. Lightweight and Agile Medium-Sized Quadruped Robots
For medium-sized quadruped robots with strict weight requirements, such as robots in a size class similar to Boston Dynamics Spot, medium-sized joint modules can be used throughout the robot.
Hip and Knee Joints:
JRM-C8567-032: 48 V, rated torque of 38 N·m, peak torque of 155 N·m, weighing only 1.2 kg.
JRM-C9577-024: Another suitable option for these joints.
Hip Abduction Joints:
JRM-C7068.5-024: 48 V, rated torque of 20 N·m, peak torque of 80 N·m, weighing 850 g.
These compact, lightweight models help reduce the overall weight of the robot while providing the required joint output.
4. Heavy-Duty and Explosion-Proof Quadruped Robots
For heavy-duty or specialized quadruped robots carrying equipment such as heavy robotic arms or firefighting systems, high-torque joint modules with a 72 VDC power supply are recommended.
Hip Abduction Joints:
JRM-C10483.5-20.4: 72 V version, rated torque of 30 N·m.
Hip Pitch and Knee Joints:
JRM-C150100-22: 72 V, peak torque of up to 600 N·m, weighing 4.2 kg. This model is designed for applications requiring high torque output.
For quadruped robots operating in specialized chemical or explosion-risk environments, dedicated explosion-proof planetary joint actuators are recommended.
Contact HONPINE for Planetary Joint Module Information
Contact HONPINE to obtain the latest catalogs and technical information on our planetary joint modules for quadruped robots.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
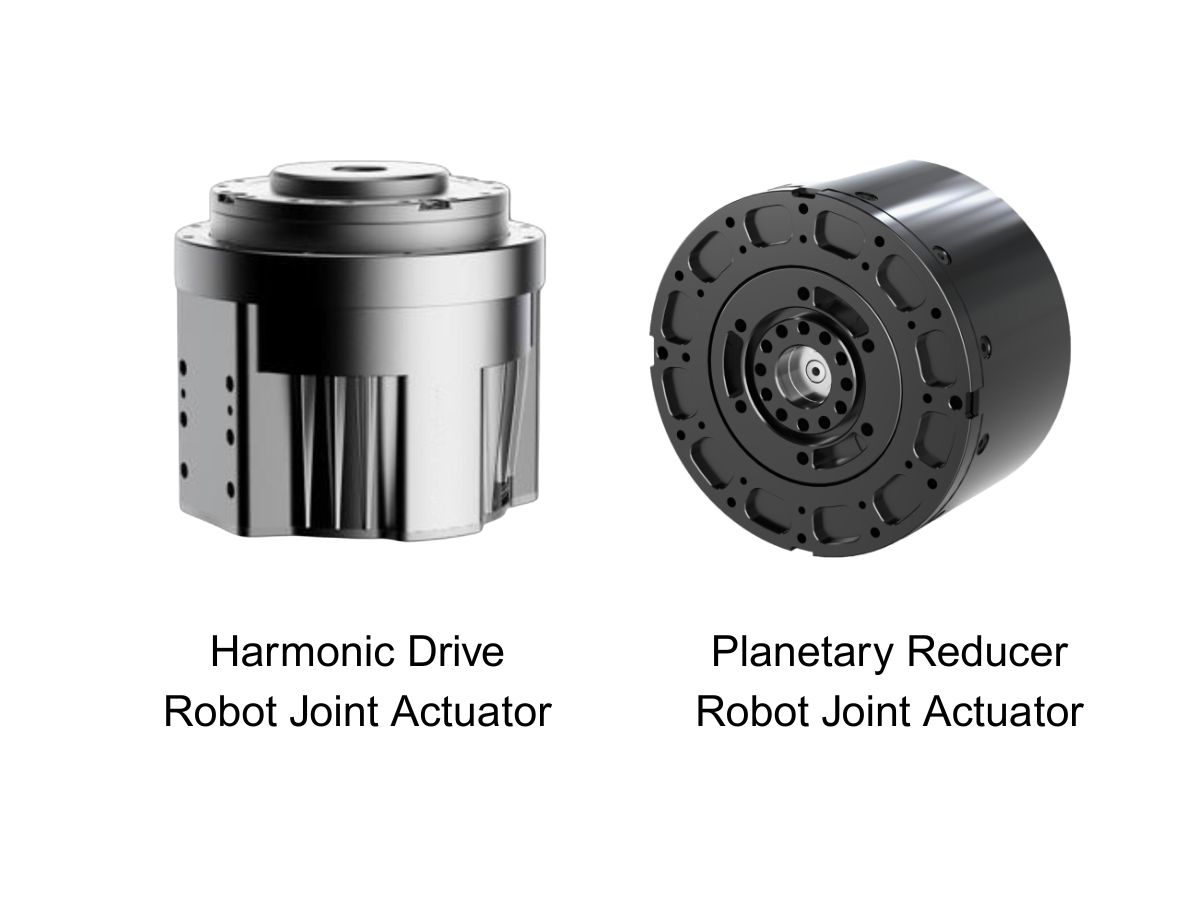
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
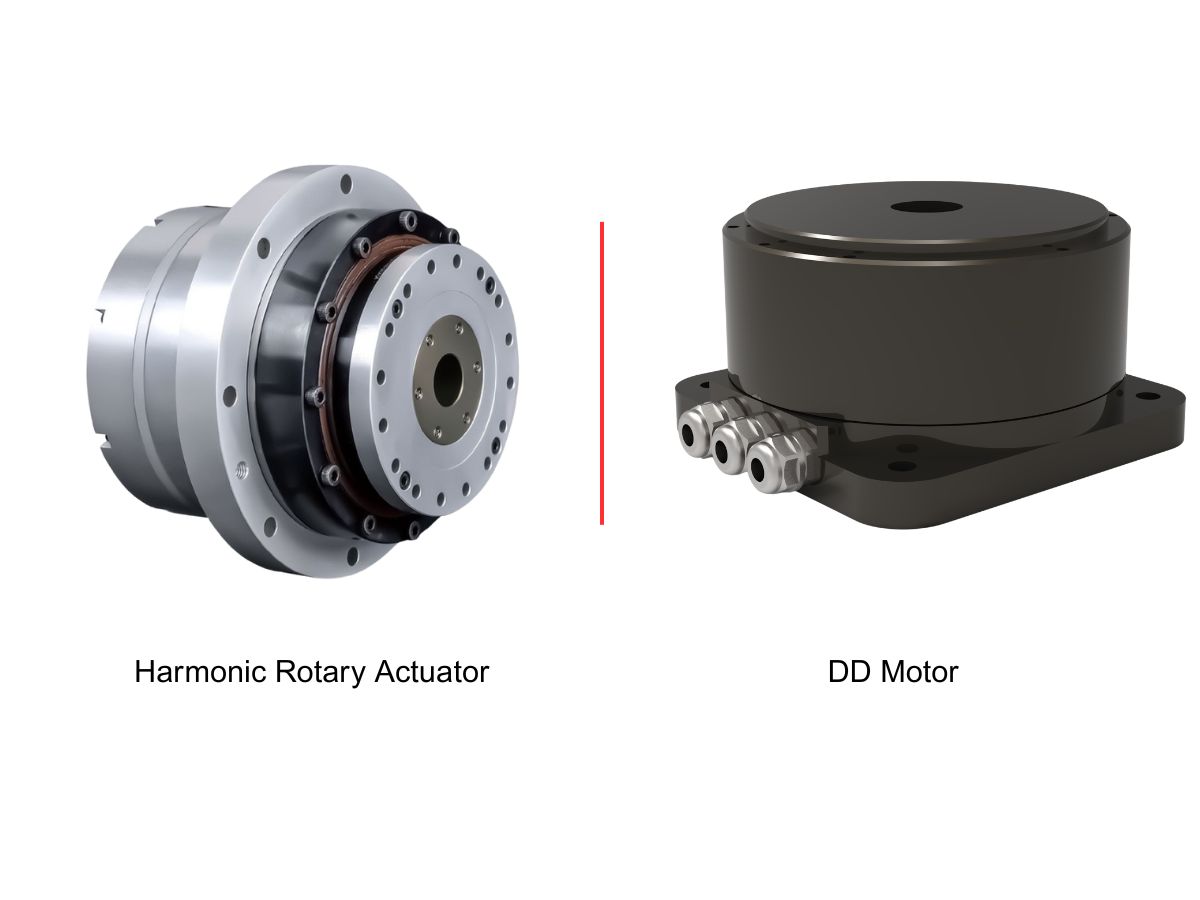
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
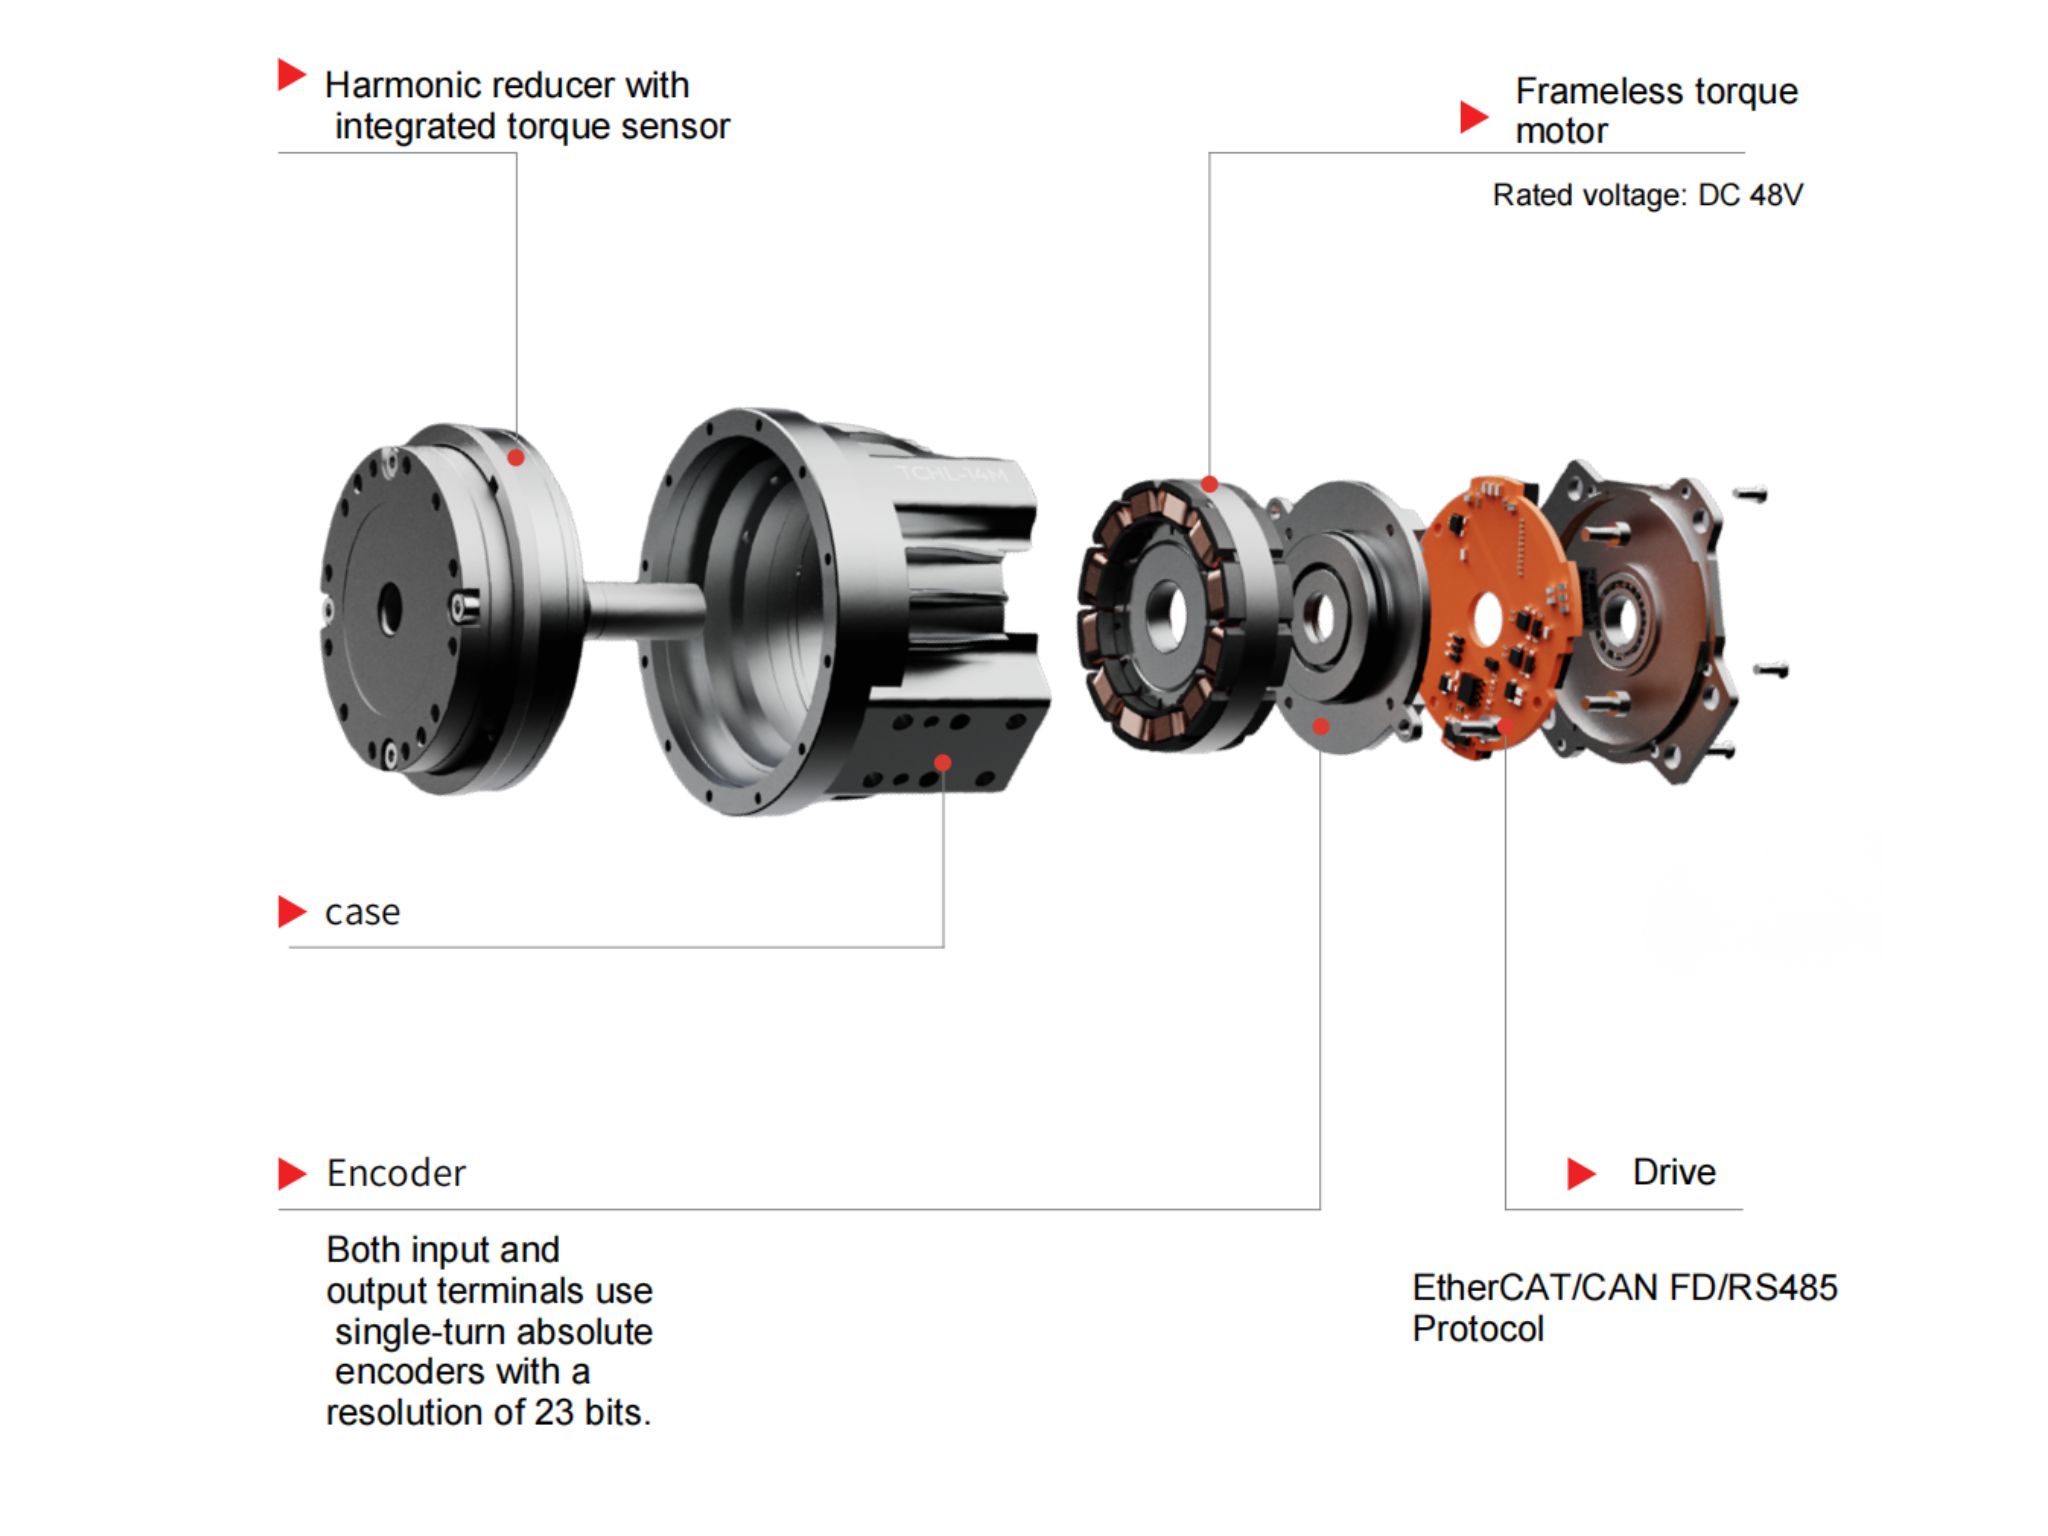
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
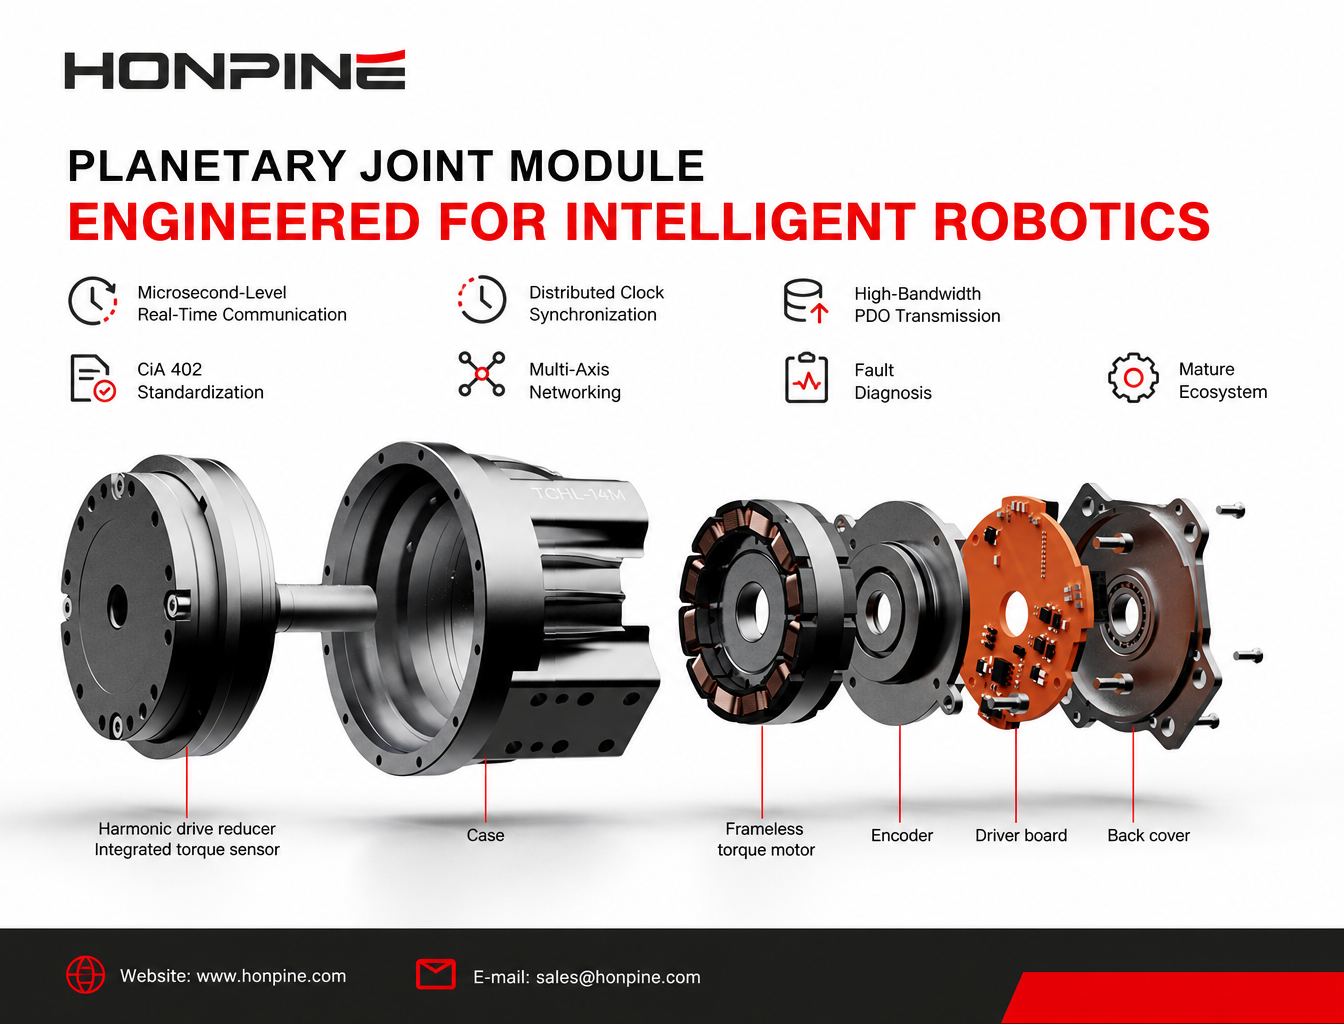
 Why Is EtherCAT Becoming the Mainstream Communication Bus for Robotic Joint Modules?Why is EtherCAT becoming the mainstream communication solution for intelligent robotic joint modules? This article explores seven key advantages, including microsecond-level real-time communication, Distributed Clock synchronization, CiA 402 standardization, high-bandwidth PDO transmission, multi-axis networking, fault diagnosis, and a mature development ecosystem. Learn how EtherCAT supports the advanced control requirements of humanoid robots, collaborative robots, and high-precision automation equipment.
 How to Select Planetary Joint Motors for Quadruped Robots?Selecting the right planetary joint motors is essential for quadruped robot performance, load capacity, and mobility. This guide explores motor selection for traditional legged robots, wheel-legged robots, lightweight agile robots, and heavy-duty or explosion-proof quadruped robots. Learn how to match HONPINE JRM planetary joint modules to different joint positions based on rated torque, peak torque, rotational speed, voltage, and weight requirements.
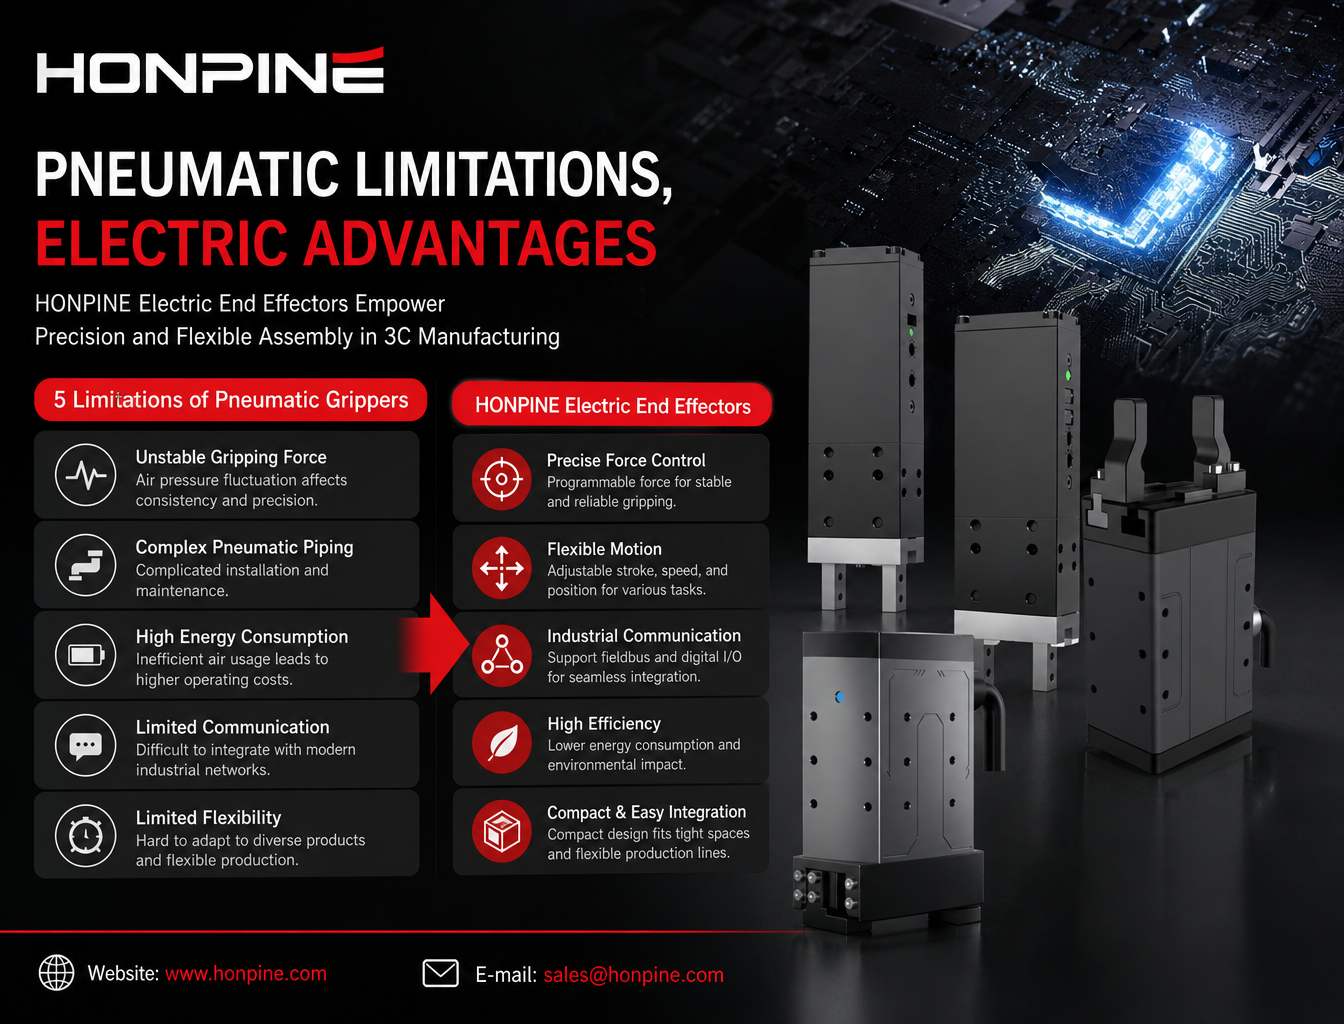
 Why Are End Effectors in 3C Automation Shifting from Pneumatic Grippers to Electric Grippers?As 3C manufacturing evolves toward thinner components, higher assembly precision, and more flexible production lines, traditional pneumatic grippers are facing increasing limitations. Fluctuating gripping force, complex pneumatic piping, high energy consumption, and limited communication capabilities make them less suitable for modern precision assembly. Electric grippers offer programmable force control, flexible motion, and industrial communication capabilities, making them an increasingly attractive alternative. In this article, we explore five major limitations of pneumatic grippers and explain how HONPINE electric end effectors support precision assembly, flexible automation, and digital manufacturing in the 3C industry.
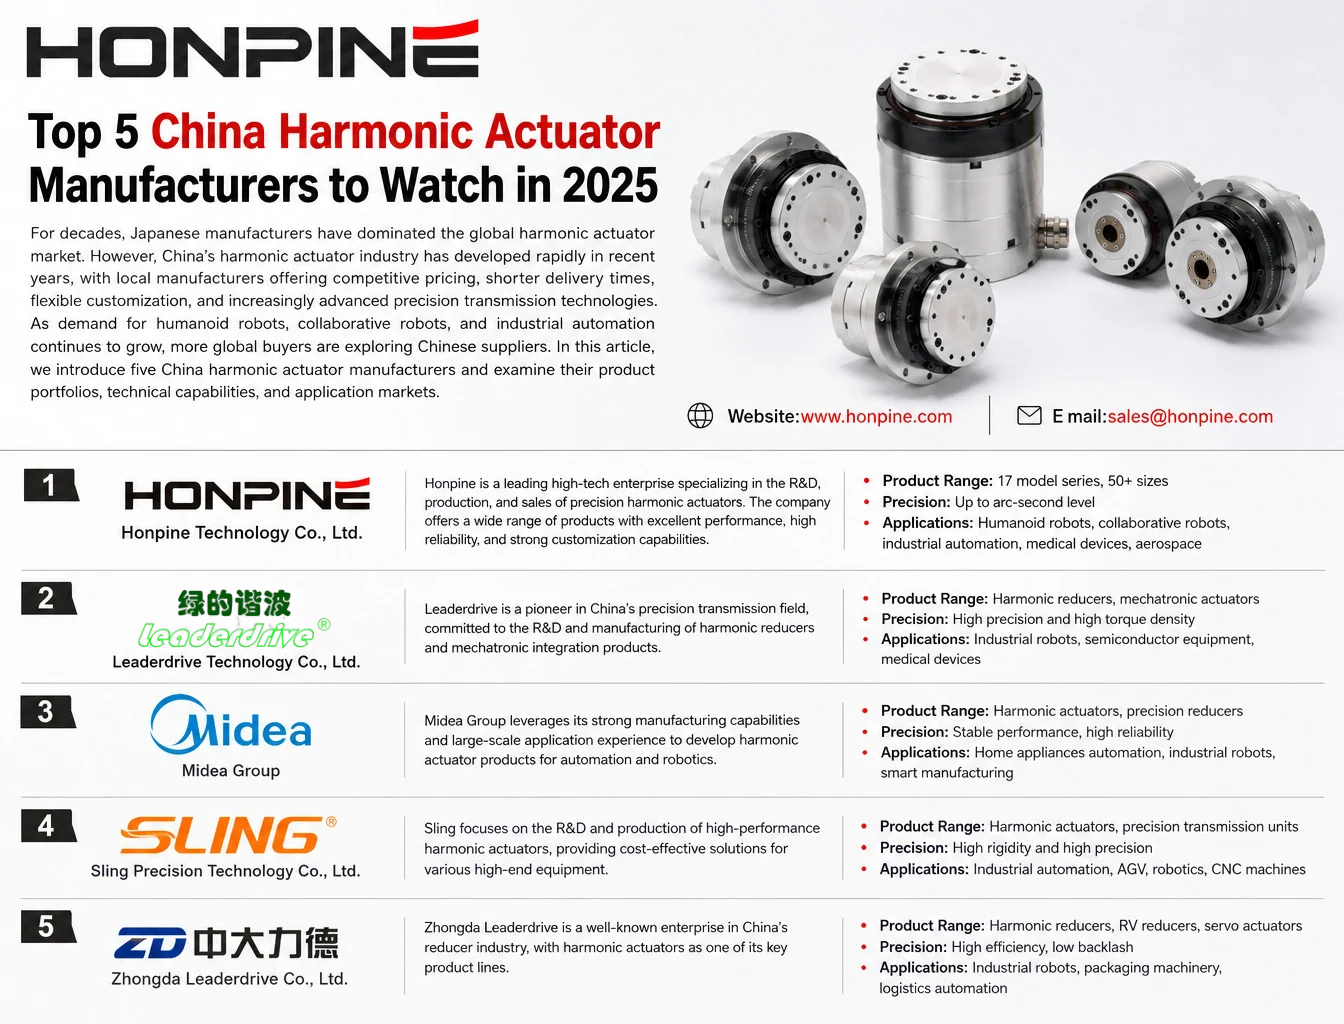
 Top 5 China Harmonic Actuator Manufacturers in 2026For decades, Japanese manufacturers have been well known in the global harmonic actuator market. However, China's harmonic actuator industry has developed rapidly in recent years, with local manufacturers offering competitive pricing, shorter delivery times, and increasingly advanced precision transmission technologies. As demand for humanoid robots, collaborative robots, and industrial automation continues to grow, more global buyers are exploring Chinese suppliers. In this article, we introduce five China harmonic actuator manufacturers and examine their products, technical capabilities, and application markets.
 Robot Joint Module Selection Guide: How to Choose the Right Joint Module Based on Load, Precision, Force Control, and Motion RequirementsRobot Joint Module Selection Guide covering torque, speed, reducers, encoders, torque sensors, drive systems, and thermal management for collaborative and humanoid robots.
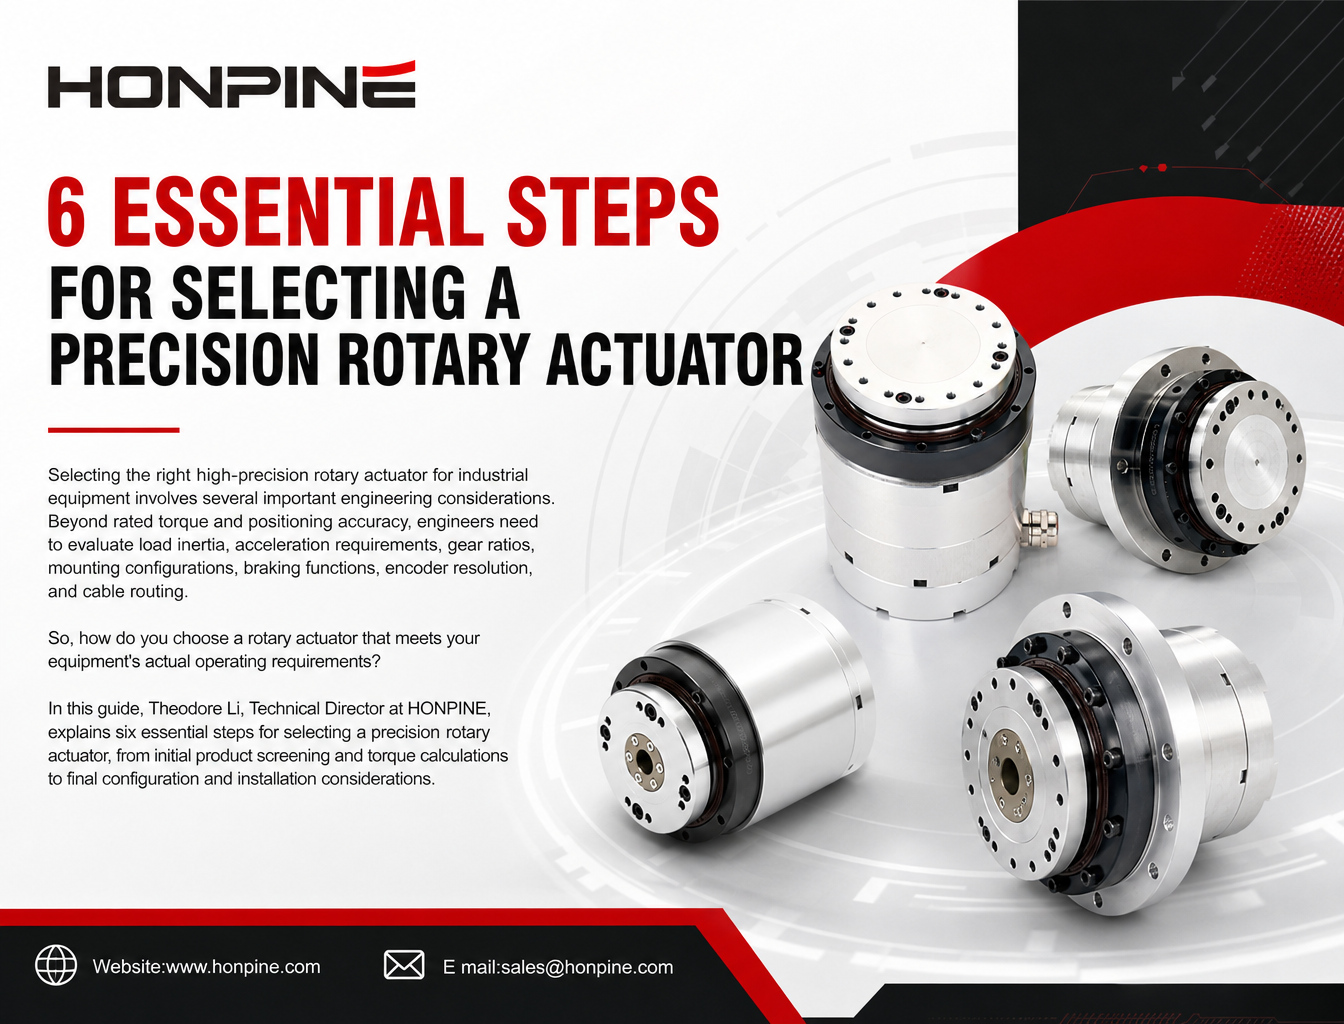
 How to Choose a High-Precision Rotary Actuator for Industrial Applications?Choosing the right precision rotary actuator requires more than checking rated torque. This guide explains how to calculate load torque, select the appropriate gear ratio, and evaluate structural configurations, mounting flanges, electromagnetic brakes, encoder resolution, and cable exit directions. Discover how HONPINE HAS, HAT, HAM, and HPG rotary actuator series meet different industrial motion control and precision positioning requirements.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 Why Is EtherCAT Becoming the Mainstream Communication Bus for Robotic Joint Modules?Why is EtherCAT becoming the mainstream communication solution for intelligent robotic joint modules? This article explores seven key advantages, including microsecond-level real-time communication, Distributed Clock synchronization, CiA 402 standardization, high-bandwidth PDO transmission, multi-axis networking, fault diagnosis, and a mature development ecosystem. Learn how EtherCAT supports the advanced control requirements of humanoid robots, collaborative robots, and high-precision automation equipment.
 How to Select Planetary Joint Motors for Quadruped Robots?Selecting the right planetary joint motors is essential for quadruped robot performance, load capacity, and mobility. This guide explores motor selection for traditional legged robots, wheel-legged robots, lightweight agile robots, and heavy-duty or explosion-proof quadruped robots. Learn how to match HONPINE JRM planetary joint modules to different joint positions based on rated torque, peak torque, rotational speed, voltage, and weight requirements.
 Why Are End Effectors in 3C Automation Shifting from Pneumatic Grippers to Electric Grippers?As 3C manufacturing evolves toward thinner components, higher assembly precision, and more flexible production lines, traditional pneumatic grippers are facing increasing limitations. Fluctuating gripping force, complex pneumatic piping, high energy consumption, and limited communication capabilities make them less suitable for modern precision assembly. Electric grippers offer programmable force control, flexible motion, and industrial communication capabilities, making them an increasingly attractive alternative. In this article, we explore five major limitations of pneumatic grippers and explain how HONPINE electric end effectors support precision assembly, flexible automation, and digital manufacturing in the 3C industry.
 Top 5 China Harmonic Actuator Manufacturers in 2026For decades, Japanese manufacturers have been well known in the global harmonic actuator market. However, China's harmonic actuator industry has developed rapidly in recent years, with local manufacturers offering competitive pricing, shorter delivery times, and increasingly advanced precision transmission technologies. As demand for humanoid robots, collaborative robots, and industrial automation continues to grow, more global buyers are exploring Chinese suppliers. In this article, we introduce five China harmonic actuator manufacturers and examine their products, technical capabilities, and application markets.
 Robot Joint Module Selection Guide: How to Choose the Right Joint Module Based on Load, Precision, Force Control, and Motion RequirementsRobot Joint Module Selection Guide covering torque, speed, reducers, encoders, torque sensors, drive systems, and thermal management for collaborative and humanoid robots.
 How to Choose a High-Precision Rotary Actuator for Industrial Applications?Choosing the right precision rotary actuator requires more than checking rated torque. This guide explains how to calculate load torque, select the appropriate gear ratio, and evaluate structural configurations, mounting flanges, electromagnetic brakes, encoder resolution, and cable exit directions. Discover how HONPINE HAS, HAT, HAM, and HPG rotary actuator series meet different industrial motion control and precision positioning requirements.
 What Kind of Robot Joint Module Should You Choose for High-Precision Humanoid Robot Control?As humanoid robots move beyond basic walking and demonstration tasks toward complex real-world applications, their joint modules must deliver more than just high torque. Precise positioning, accurate torque control, structural stiffness, and dynamic response all play important roles in performing delicate operations. So, what kind of joint module should you choose for a humanoid robot designed to handle high-precision tasks? In this article, Theodore Li, Technical Director at HONPINE, introduces the HAG Harmonic Joint Module and explains five key features that make it suitable for demanding humanoid robot applications.
 HONPINE HPJM Harmonic Joint Motor: Position Mode vs. Speed Mode – How to Choose the Right Control Mode?Position mode and speed mode serve different motion-control requirements in robotic systems. Using the HONPINE HPJM harmonic joint motor as an example, this article explains their control architectures, operating principles, key differences, and application scenarios. From humanoid robot joints and rehabilitation exoskeletons to mobile robot drive wheels and continuous-rotation test systems, discover how to select the appropriate control mode based on motion objectives, mechanical loads, and system safety requirements.
 3 Best Harmonic Gear Reducers for Semiconductor EquipmentSemiconductor manufacturing equipment requires high-precision motion control, compact mechanical structures, and reliable transmission performance. From wafer handling robots and OHT systems to lithography and metrology equipment, different applications place different demands on harmonic gear reducers. In this article, Theodore Li, Technical Director at HONPINE, introduces three harmonic gear reducer solutions: the FHG hollow-shaft series, FHD ultra-thin series, and FSD ultra-flat series. We will also examine 10 key technical parameters engineers should consider when selecting a harmonic gear reducer for semiconductor equipment, including rated torque, backlash, torsional rigidity, hollow shaft diameter, and permissible moment load.