Should You Choose a T-Type or Straight-Type Harmonic Joint Module for a Collaborative Robot?
Hello, I’m Theodore Li, Technical Director at HONPINE. Today, I’ll introduce two harmonic joint module solutions for collaborative robotic arms: the TCHL straight-type joint module and the HTS T-type joint module.
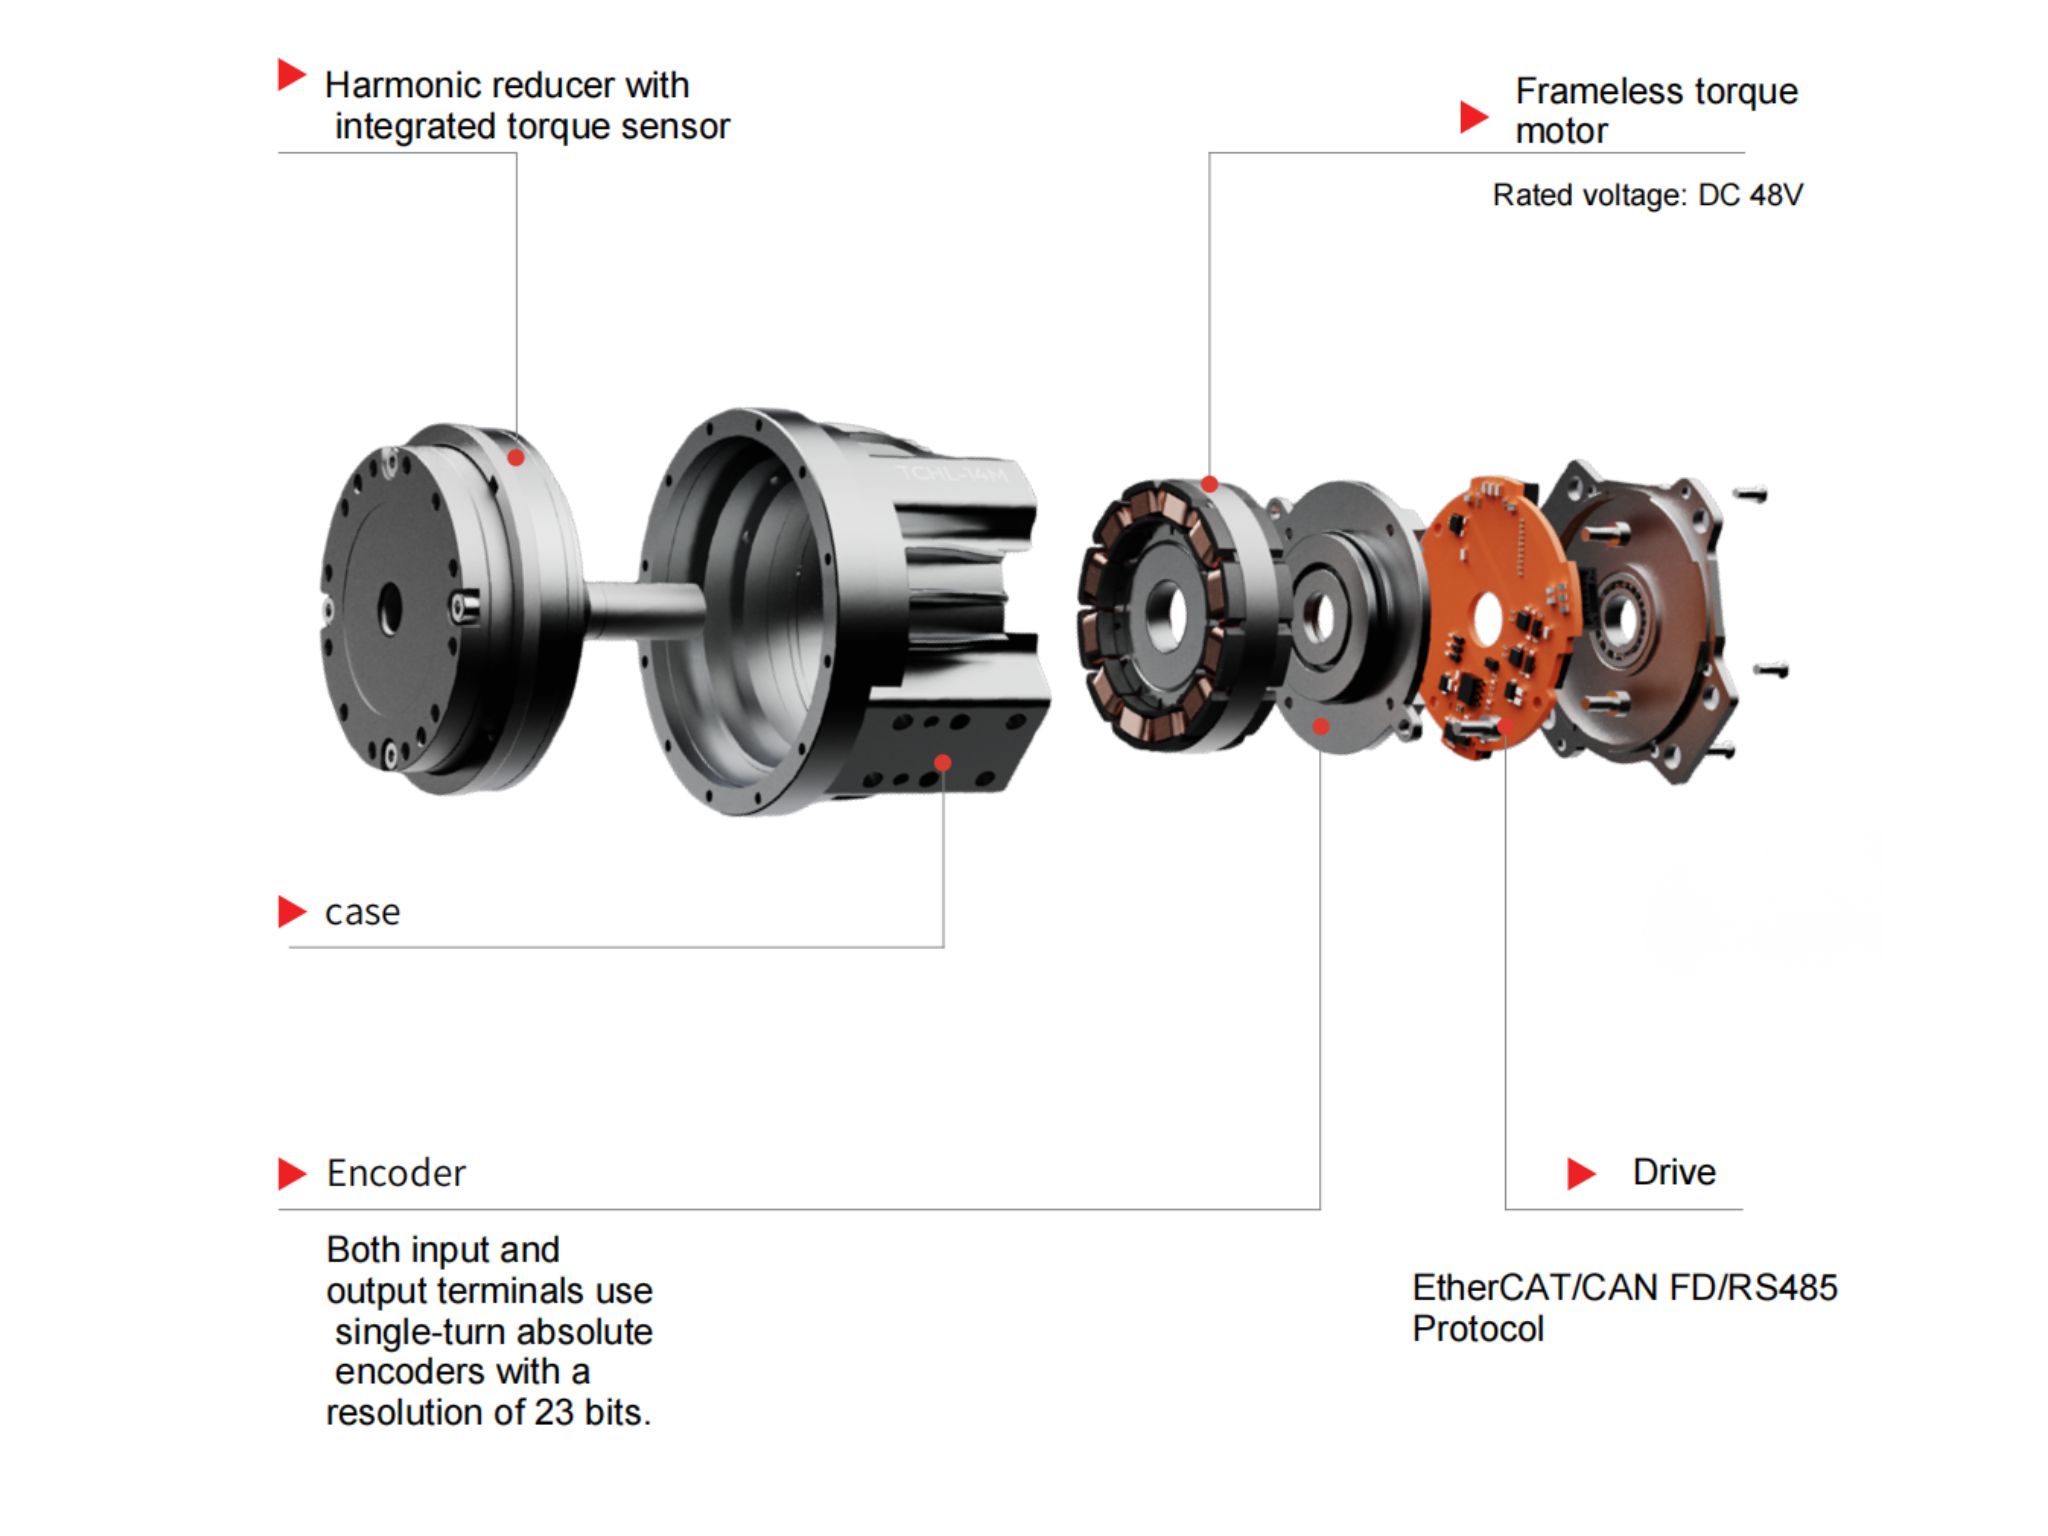
Integrated harmonic joint modules are key drive units in collaborative robots (cobots). By integrating a harmonic drive reducer, torque motor, absolute encoders, drive electronics, and an optional holding brake into a compact assembly, they simplify mechanical integration and provide closed-loop servo control.
However, choosing the right harmonic joint module involves more than comparing torque ratings or positioning accuracy. The module’s structural configuration directly affects installation space, arm geometry, internal cable routing, mechanical stiffness, and the risk of interference between moving links.
In this guide, I’ll explain the structural characteristics, advantages, limitations, and typical applications of the TCHL straight-type and HTS T-type harmonic joint modules to help engineers select the right solution for their collaborative robot designs.
1. General Selection Principles for Collaborative Robot Joint Modules
Selecting a joint module for a collaborative robotic arm requires a comprehensive evaluation of five factors: torque and reduction ratio, encoder performance, communication protocol, environmental conditions, and mechanical configuration.
1.1 Match Torque and Reduction Ratio to the Operating Conditions
The first step is to determine the continuous torque and peak torque required at each joint. The selected module must accommodate the actual load profile, including acceleration, deceleration, external forces, and short-duration dynamic loads.
The joint module series described in this guide covers multiple frame sizes, with outer diameters of 70, 80, 90, 110, 142, and 170 mm. Available reduction ratios include 51:1, 81:1, 101:1, and 121:1, depending on the specific model.
In general, a higher reduction ratio provides greater torque multiplication but reduces output speed for a given motor speed. A lower reduction ratio allows higher output speed but provides less torque multiplication.
The final choice should be based on the actuator’s torque-speed characteristics, the robot’s motion profile, and the required duty cycle.
Important: Avoid operating a joint module beyond its permitted torque limits, particularly for prolonged periods. Overloading can accelerate wear or damage the reducer and other components, potentially compromising joint control and reliability.
For vertically mounted joints that must hold a load against gravity, consider a brake-equipped configuration. A suitable holding brake can help prevent unintended shaft rotation when power is removed. For horizontal joints with limited gravitational loading, a brake-free configuration may be appropriate, depending on the application’s safety requirements.
1.2 Evaluate Encoder Configuration and Positioning Accuracy
The joint modules described in the original specifications use a 17-bit single-turn and 16-bit multi-turn magnetic absolute encoder configuration. Battery backup preserves multi-turn position information when power is removed, allowing the system to retain position data without requiring a reference-homing procedure after every power cycle, provided the encoder backup system is correctly maintained.
The output-side angular resolution is influenced by the encoder configuration and reduction ratio. A higher reduction ratio can provide finer theoretical output-angle increments for a given motor-side encoder resolution. However, actual positioning accuracy also depends on reducer transmission errors, mechanical deformation, backlash characteristics, mounting precision, and control performance.
When selecting a module, engineers should also check the following mechanical accuracy parameters:
Output flange face runout
Output shaft radial runout
Coaxiality
Parallelism
These tolerances influence the alignment and repeatability of the assembled robotic arm. HONPINE’s measured mechanical accuracy data for each model should be checked during the design and validation process.
1.3 Choose the Appropriate Communication Protocol
The communication protocol is another important consideration when integrating multiple joint modules into a collaborative robotic arm.
For the product configurations described here, the model suffix identifies the communication option: C for CANopen and E for EtherCAT. Confirm the exact suffix and available protocol for the selected TCHL or HTS model before ordering.
EtherCAT (E)
EtherCAT supports high-speed, deterministic communication and synchronized control across multiple axes. It is suitable for collaborative robots with six or more joints, particularly where coordinated motion and real-time control are important.
It can be integrated with compatible EtherCAT master controllers, including Beckhoff-based systems.
CANopen (C)
CANopen can provide a practical solution for systems that prioritize relatively simple network architecture and cost-effective integration. It may be suitable for robots with fewer axes or less demanding synchronization requirements.
Compatible CANopen master controllers and PLCs can be used, subject to device profiles and controller support.
The appropriate protocol depends on the complete control architecture, communication cycle requirements, synchronization performance, and controller compatibility.
1.4 Consider Environmental Conditions and Mechanical Constraints
Before selecting a joint module, verify that its operating environment meets the product specifications.
The environmental conditions provided for the series are:
Operating temperature: 0–40°C
Storage temperature: −20–60°C
Relative humidity: 20–80% RH, non-condensing
Protection rating: IP54
Recommended operating altitude: below 1,000 m
These values should be confirmed against the datasheet for the exact model and configuration.
Control cabinets should also provide adequate heat dissipation to prevent internal temperatures from exceeding the permitted operating range.
From a mechanical perspective, engineers should check the hollow bore diameter, flange mounting-hole pattern, arm-link length, and potential interference throughout the robot’s complete range of motion.
This is where the structural differences between the TCHL straight-type and HTS T-type modules become particularly important.
1.5 Understand the Structural Difference Between TCHL and HTS
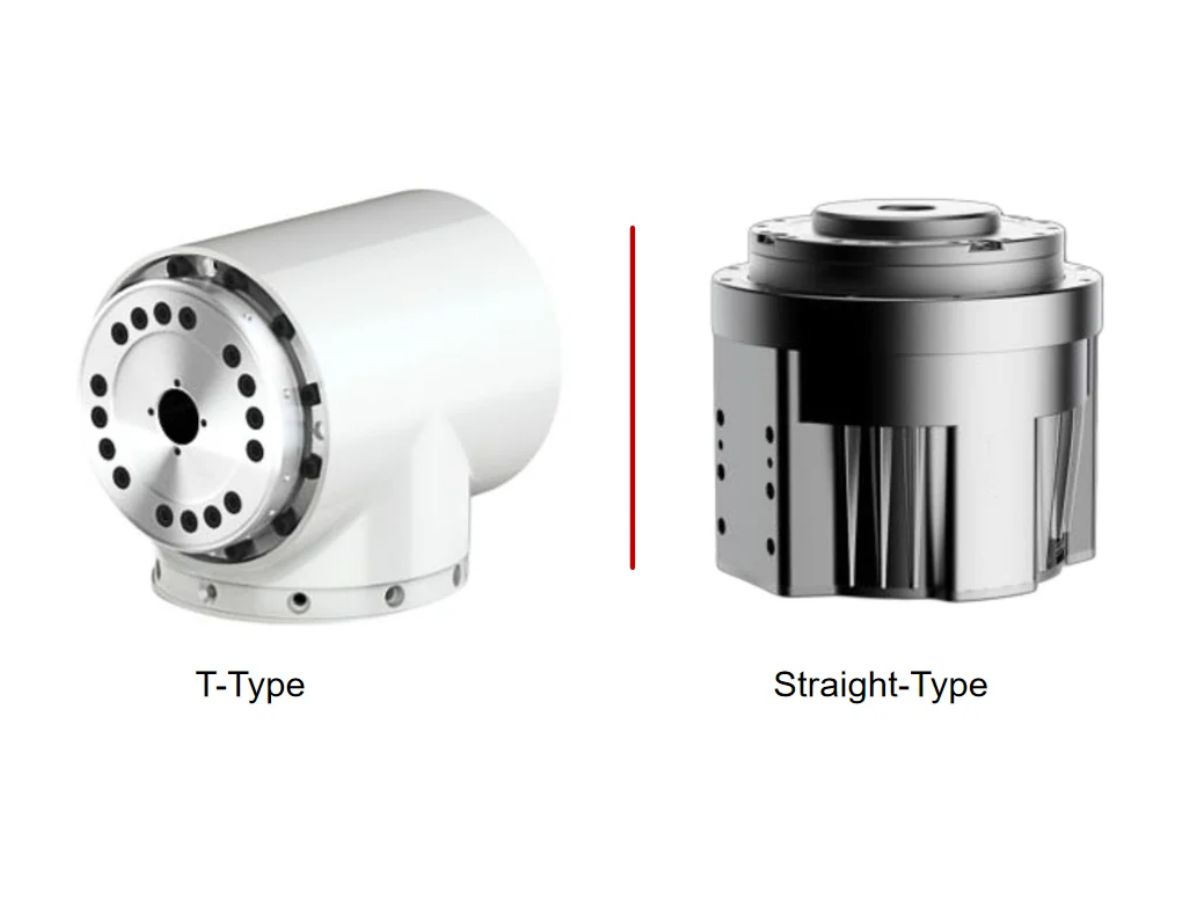
The TCHL straight-type joint moduleand the HTS T-type joint module differ primarily in their output flange geometry and installation arrangement.
The TCHL straight-type uses a straight, cylindrical configuration with the output flange arranged concentrically with the module body.
The HTS T-type uses an offset output flange arrangement that allows the connected mechanical structure to be positioned differently relative to the cylindrical module body.
These differences influence the overall dimensions, mounting arrangement, and packaging of the robotic arm.
When comparing corresponding models, verify the specifications of each configuration rather than assuming that every internal component or electrical characteristic is identical.
2. Advantages of the TCHL Straight-Type Harmonic Joint Module
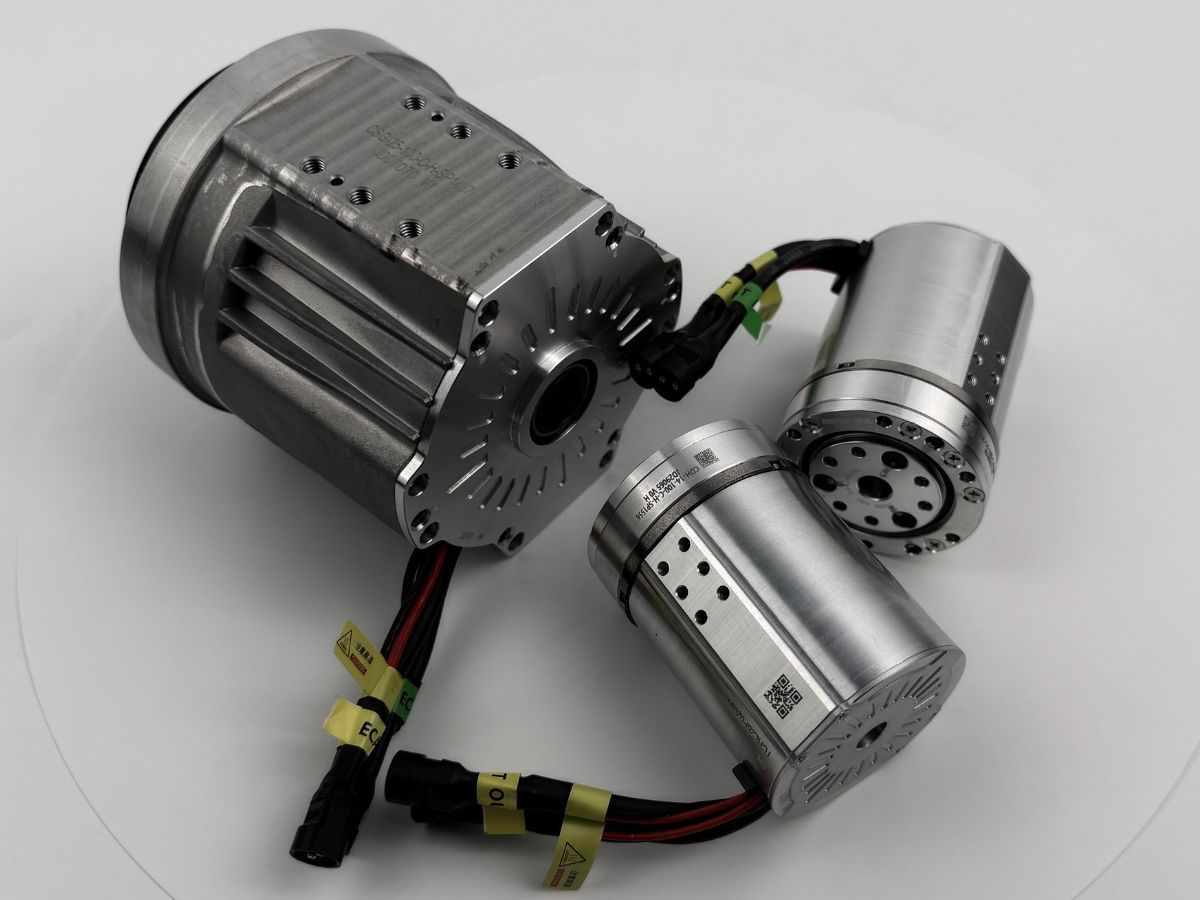
The TCHL straight-type joint module features a cylindrical body with a concentric output flange. The output flange is arranged around the module’s central axis, creating a straight, compact form factor.
Depending on the model, the product drawings may include configurations such as TCHL-14-70 and TCHL-17-80. Confirm the exact model designation against the current HONPINE product catalogue.
2.1 Compact Radial Dimensions for Space-Constrained Designs
Because the module body and output flange share a common axis, the straight-type configuration has no additional lateral flange offset.
This can help reduce radial space requirements in robotic joints where the module must fit inside a cylindrical arm link or within a nested mechanical assembly.
The hollow center also provides a potential route for internal cables, pneumatic tubing, and other service lines, subject to the available bore diameter and installation requirements.
For collaborative robot designs with limited radial clearance, the TCHL straight-type configuration can simplify packaging and help maintain a compact external profile.
2.2 Concentric Flange Design for Load Transfer
The concentric output flange provides a circular mounting interface around the central bore. Mounting bolts can be distributed around the flange according to the specified hole pattern, helping transfer loads into the reducer output structure.
This arrangement can be advantageous for joints subjected to bending moments and overturning loads, provided the module is correctly sized and mounted.
The actual load capacity and stiffness depend on the reducer, output bearing arrangement, flange geometry, bolt specification, mounting interface, and external load conditions.
For base and shoulder joints that carry substantial bending moments, engineers should compare the module’s permissible radial, axial, and moment loads with the actual loads generated by the robot.
The product manual should be used to verify the correct bolt sizes and tightening torques for each model.
2.3 Simplified Mechanical Design and Manufacturing
The straight cylindrical profile can simplify the design of robotic arm housings and link structures.
In many applications, the arm link can be designed around a cylindrical or concentric structure with mounting interfaces at each end. This may reduce the need for custom offset brackets or complex external contours.
A simpler housing can also make machining, assembly, and maintenance more straightforward, depending on the overall mechanical design.
For manufacturers developing multiple collaborative robot models, a standardized straight-type joint interface may help simplify the reuse of mechanical components.
2.4 Broad Compatibility with Conventional Robotic Arm Architectures
Straight-type joint modules are well suited to robotic architectures in which adjacent links are connected through concentric mounting interfaces.
They can be considered for base, shoulder, and elbow joints, as well as rotary positioning mechanisms and other applications where a straight cylindrical form is beneficial.
When a TCHL module is integrated into a control system, the communication protocol, commissioning tools, and software configuration must match the selected product version. Structural changes between module configurations should not, by themselves, be assumed to require a different control strategy.
2.5 Limitations of the TCHL Straight-Type Configuration
The main limitation of the straight-type configuration appears when the robotic arm requires a compact 90-degree connection between adjacent links.
Because the output flange is arranged concentrically with the module body, the overall assembly may require additional axial space when two links are connected at a right angle.
This can increase the joint assembly’s thickness and extend the distance between adjacent link structures. In a compact wrist mechanism, this additional space may reduce the available motion envelope and increase the risk of self-interference.
An additional adapter bracket may be required, depending on the mechanical layout.
2.6 Typical Applications for TCHL Straight-Type Joint Modules
The TCHL straight-type configuration is worth considering for:
Base and shoulder joints in collaborative robotic arms
Elbow joints with concentric mounting arrangements
Rotary positioning tables and mechanisms
Applications requiring a compact radial profile
Robot structures designed around cylindrical arm links
Joints that experience substantial bending moments and require an appropriate concentric mounting interface
The final selection must still be validated against the module’s rated loads, dimensions, and installation requirements.
3. Advantages of the HTS T-Type Harmonic Joint Module
The HTS T-type joint module features an offset output flange arrangement. The flange is positioned laterally relative to the cylindrical module body, creating a configuration that can accommodate right-angle connections between adjacent robotic links.
This geometry can be particularly useful in compact collaborative robot wrists, where several rotational axes must fit within a limited installation space.
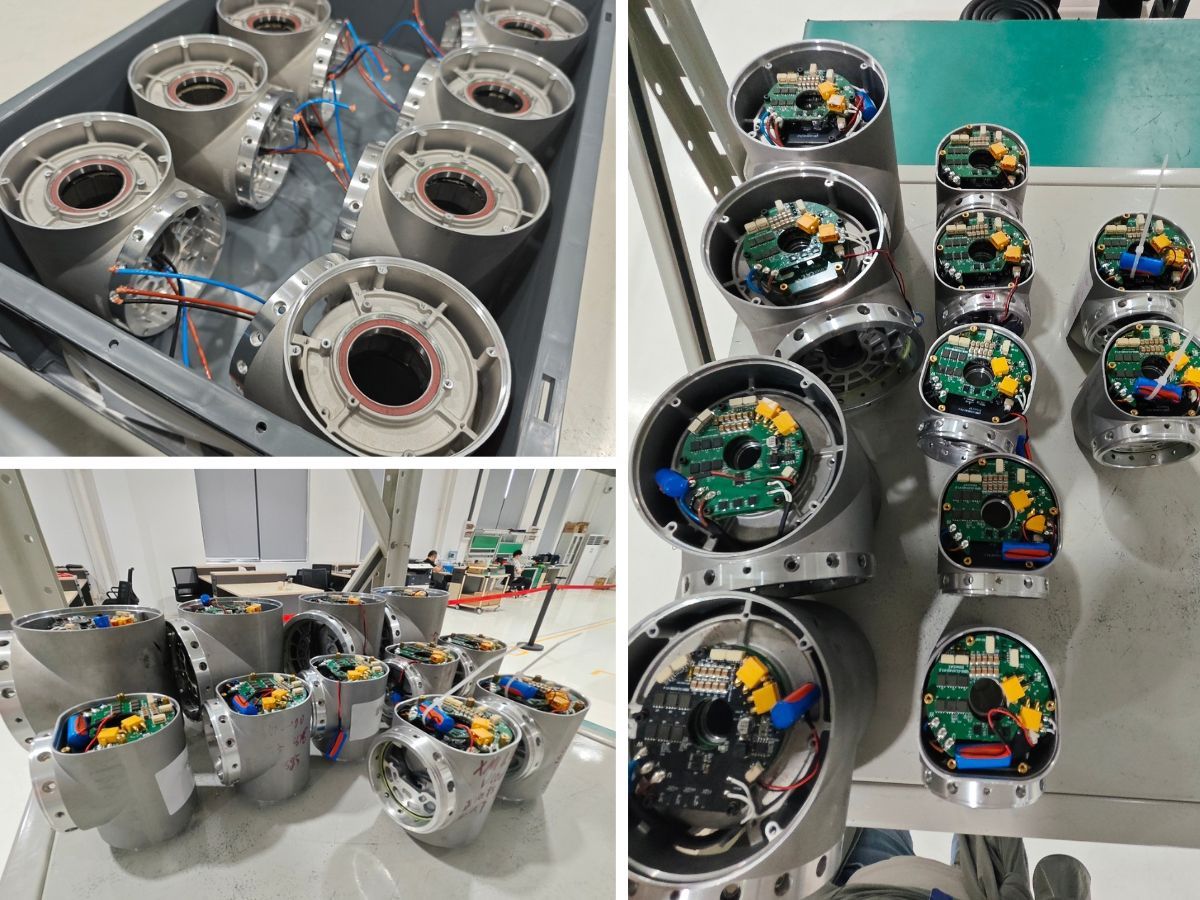
3.1 Right-Angle Mounting for Reduced Axial Space
The offset output flange allows the connected link structure to be positioned differently from that of a concentric straight-type module.
In suitable mechanical layouts, this can simplify a 90-degree connection between adjacent arm links and reduce the axial thickness of the assembled joint structure.
The advantage is particularly relevant to the wrist axes of a collaborative robot, commonly referred to as axes 4, 5, and 6.
These joints are often tightly packaged because several rotation axes must be accommodated close to the end effector.
By reducing the space required for the joint connection, the HTS T-type configuration may help create a more compact wrist and reduce the risk of interference when the robot reaches confined workspaces.
The actual improvement depends on the link geometry, output flange dimensions, mounting arrangement, and complete motion envelope.
3.2 Simplified Multi-Axis Wrist Design with Fewer Adapter Components
A conventional straight-type module may require an additional L-shaped adapter bracket to achieve a right-angle connection between adjacent links.
Depending on the design, this bracket can add mass, increase the number of components, and introduce additional mounting interfaces that must be manufactured and assembled accurately.
The HTS T-type configuration integrates the offset into the module’s structural arrangement, potentially reducing the need for separate adapter components.
This can help simplify the mechanical design of compact multi-axis wrist assemblies.
Reducing unnecessary brackets and interfaces may also lower the end-effector assembly’s mass and improve the robot’s payload-to-self-weight ratio, provided the resulting structure meets the required stiffness and strength criteria.
3.3 Hollow-Center Routing for Internal Cables
The T-type configuration can also support internal cable routing through the module’s hollow center, subject to the specific model’s bore dimensions and mechanical arrangement.
Cables and service lines can be routed through the module body and connected to the offset output structure according to the installation design.
Internal routing helps protect cables from external snagging, abrasion, and interference with surrounding equipment.
For collaborative robots that require compact cable management, this can be especially useful around the wrist, where external cable loops may interfere with nearby objects or limit the usable motion range.
Engineers should verify the cable bend radius, connector dimensions, permissible cable twist, and clearance throughout the complete joint motion.
3.4 Limitations of the HTS T-Type Configuration
Despite its packaging advantages, the T-type design is not the best choice for every joint.
Larger lateral envelope
The offset output flange protrudes beyond the central cylindrical profile. This can increase the robot’s overall width or radial envelope.
For base and shoulder joints, where the robot may require a narrow external profile, this additional lateral projection can be a disadvantage.
Eccentric loading considerations
Because the output flange is offset relative to the module body, the mechanical design must account for the resulting load path and any additional bending moments generated by the external structure.
For heavy loads or large bending moments, engineers should verify the module’s allowable loads and ensure that the housing and mounting interfaces provide sufficient strength and stiffness.
More complex housing geometry
The offset shape may require a customized arm-link housing rather than a simple cylindrical enclosure.
This can increase machining and mechanical design complexity, depending on the robot’s architecture and manufacturing process.
The HTS T-type configuration should therefore be selected when its packaging benefits justify the additional design considerations.
3.5 Typical Applications for HTS T-Type Joint Modules
The HTS T-type configuration is worth considering for:
Compact wrist assemblies in collaborative robotic arms
Right-angle connections between adjacent robotic links
Multi-axis wrist mechanisms with limited axial space
Robotic arms that must reach into confined work areas
Designs where reducing adapter brackets and distal joint mass is a priority
Applications that benefit from internal cable routing through a compact joint structure
The selected model must still satisfy the required torque, speed, stiffness, and permissible load specifications.
4. TCHL Straight-Type vs. HTS T-Type: How to Choose
The most important difference between these two configurations is their mechanical layout, not simply their torque rating.
4.1 When Should You Choose the TCHL Straight-Type Module?
Choose the TCHL straight-type configuration as a starting point when the robot’s mechanical architecture benefits from a concentric cylindrical module.
It is particularly worth evaluating for base and shoulder joints, rotary positioning applications, and arm links where radial clearance is limited.
The straight-type design may also simplify housing design when the arm structure uses cylindrical components and conventional concentric mounting interfaces.
4.2 When Should You Choose the HTS T-Type Module?
Choose the HTS T-type configuration as a starting point when the robotic arm requires a compact right-angle connection or when the axial thickness of a multi-axis wrist assembly must be minimized.
Its offset output flange can simplify mechanical packaging and potentially reduce the need for separate adapter brackets.
However, engineers should also evaluate the increased lateral envelope, load path, housing design, and available clearance throughout the robot’s range of motion.
4.3 Can Both Configurations Be Used in the Same Collaborative Robot?
Yes. A collaborative robot can use different joint module configurations at different positions when the mechanical architecture requires it.
For example, a robot may use TCHL straight-type modules at the base and shoulder, where concentric mounting is advantageous, and HTS T-type modules in a compact wrist assembly, where a right-angle layout helps reduce packaging space.
This mixed configuration can provide greater mechanical design flexibility, provided that the selected modules meet the required torque, speed, communication, and installation specifications.
5. Final Recommendations for Collaborative Robot Joint Module Selection
Choosing between a TCHL straight-type harmonic joint module and an HTS T-type harmonic joint module should begin with the mechanical structure of the robotic arm.
The TCHL straight-type configuration is generally worth considering when a concentric cylindrical design, compact radial profile, and straightforward mounting arrangement are priorities.
The HTS T-type configuration is particularly worth considering when right-angle link connections, compact wrist packaging, and reduced axial space are important.
Neither configuration is universally superior. The appropriate choice depends on the joint position, available installation space, external loads, required motion range, and overall robot architecture.
Before finalizing a design, engineers should verify the exact model dimensions, torque-speed performance, encoder specifications, communication protocol, permissible loads, and brake options against the applicable product documentation.
6. Contact HONPINE for Collaborative Robot Joint Module Solutions
At HONPINE, we understand that collaborative robot designers need more than a compact actuator. They need a joint module configuration that fits the mechanical architecture, supports the required motion performance, and simplifies system integration.
The TCHL straight-type and HTS T-type harmonic joint modules provide two different structural approaches to collaborative robot joint design.
Whether you are developing a six-axis collaborative robotic arm, a compact robotic wrist, or a customized automation system, selecting the appropriate configuration early in the design process can help reduce mechanical complexity and improve space utilization.
Contact HONPINE to discuss your collaborative robot joint module requirements and identify a suitable configuration for your application.
About Author
Theodore Li serves as the Technical Director at HONPINE, overseeing the R&D strategy for replication products, guiding team selection, and managing both pre-sales and after-sales operations.

Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 Should You Choose a T-Type or Straight-Type Harmonic Joint Module for a Collaborative Robot?Choosing the right harmonic joint module is essential when designing a compact, high-performance collaborative robot. Should you use a TCHL straight-type or an HTS T-type harmonic joint module? Although both configurations can support precise robotic motion, their different output flange geometries affect installation space, link connections, cable routing, and mechanical integration. In this guide, Theodore Li, Technical Director at HONPINE, explains the key differences between the two designs, their advantages and limitations, and how to select the most suitable configuration for your collaborative robotic arm.
 The Complete Harmonic Joint Actuator Solution for Humanoid Robots: HPJM Series Selection GuideA complete guide to selecting harmonic joint actuators for humanoid robots. Explore HONPINE HPJM models for wrist, elbow, shoulder, waist, hip, knee, and ankle joints, with practical considerations for torque capacity, reduction ratios, dynamic response, and holding brake configurations.
 Why Are Harmonic Drive Actuators Ideal for Space-Constrained Industrial Automation Equipment?In modern industrial automation, limited installation space often makes mechanical design more challenging. Harmonic drive actuators offer a compact motion-control solution by integrating key drive components into a single unit. Their high reduction ratios, streamlined mechanical structures, and flexible mounting options can help equipment manufacturers reduce space requirements, simplify assembly, and optimize internal layouts. This article explores four ways integrated harmonic drive actuators support space-saving designs in industrial automation equipment.
 STO vs. Holding Brake in Robot Joint Modules: What Is the Difference for Robot Safe Control?STO (Safe Torque Off) and holding brakes play different roles in robot joint safety. While STO prevents a motor from generating driving torque, a holding brake mechanically resists joint movement and helps retain loads when the motor is disabled. Understanding the difference is essential when selecting a robot joint module for humanoid robots, collaborative robots, and industrial automation. In this article, Theodore Li, Technical Director at HONPINE, explains how these functions work, their limitations, and when both should be considered in a harmonic integrated joint actuator such as the HONPINE HAG series.
 AGV Robot Steering Drive Wheel: A Comprehensive Guide to Components, Applications, and SelectionAn AGV steering drive wheel integrates traction and active steering to support flexible movement in industrial mobile robots. This guide explains its main components, working principles, industrial applications, and key selection factors, including load capacity, traction torque, steering torque, wheel diameter, speed, and control interfaces. Discover how to choose a suitable steering drive module for AGVs, AMRs, autonomous forklifts, and heavy-duty material handling systems.
 How Does a Harmonic Joint Actuator with a Torque Sensor Improve Robot Force Control?Learn how the HONPINE TCHL harmonic joint actuator uses an integrated output torque sensor to support force feedback, collision detection, compliant assembly, rehabilitation robotics, and teleoperation.


Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 Should You Choose a T-Type or Straight-Type Harmonic Joint Module for a Collaborative Robot?Choosing the right harmonic joint module is essential when designing a compact, high-performance collaborative robot. Should you use a TCHL straight-type or an HTS T-type harmonic joint module? Although both configurations can support precise robotic motion, their different output flange geometries affect installation space, link connections, cable routing, and mechanical integration. In this guide, Theodore Li, Technical Director at HONPINE, explains the key differences between the two designs, their advantages and limitations, and how to select the most suitable configuration for your collaborative robotic arm.
 The Complete Harmonic Joint Actuator Solution for Humanoid Robots: HPJM Series Selection GuideA complete guide to selecting harmonic joint actuators for humanoid robots. Explore HONPINE HPJM models for wrist, elbow, shoulder, waist, hip, knee, and ankle joints, with practical considerations for torque capacity, reduction ratios, dynamic response, and holding brake configurations.
 Why Are Harmonic Drive Actuators Ideal for Space-Constrained Industrial Automation Equipment?In modern industrial automation, limited installation space often makes mechanical design more challenging. Harmonic drive actuators offer a compact motion-control solution by integrating key drive components into a single unit. Their high reduction ratios, streamlined mechanical structures, and flexible mounting options can help equipment manufacturers reduce space requirements, simplify assembly, and optimize internal layouts. This article explores four ways integrated harmonic drive actuators support space-saving designs in industrial automation equipment.
 STO vs. Holding Brake in Robot Joint Modules: What Is the Difference for Robot Safe Control?STO (Safe Torque Off) and holding brakes play different roles in robot joint safety. While STO prevents a motor from generating driving torque, a holding brake mechanically resists joint movement and helps retain loads when the motor is disabled. Understanding the difference is essential when selecting a robot joint module for humanoid robots, collaborative robots, and industrial automation. In this article, Theodore Li, Technical Director at HONPINE, explains how these functions work, their limitations, and when both should be considered in a harmonic integrated joint actuator such as the HONPINE HAG series.
 AGV Robot Steering Drive Wheel: A Comprehensive Guide to Components, Applications, and SelectionAn AGV steering drive wheel integrates traction and active steering to support flexible movement in industrial mobile robots. This guide explains its main components, working principles, industrial applications, and key selection factors, including load capacity, traction torque, steering torque, wheel diameter, speed, and control interfaces. Discover how to choose a suitable steering drive module for AGVs, AMRs, autonomous forklifts, and heavy-duty material handling systems.
 How Does a Harmonic Joint Actuator with a Torque Sensor Improve Robot Force Control?Learn how the HONPINE TCHL harmonic joint actuator uses an integrated output torque sensor to support force feedback, collision detection, compliant assembly, rehabilitation robotics, and teleoperation.
 Ultra-Compact Harmonic Joint Module with a 6 mm Hollow ShaftAs humanoid robots and compact robotic systems evolve, joint modules must deliver high torque density, precise motion control, and flexible cable routing within increasingly limited installation space. The HONPINE HPJM-RE30-40-PRO harmonic joint module addresses these challenges with a compact design, a 6 mm hollow shaft, dual-encoder feedback, and an integrated motor and FOC drive. In this article, we explore its key design features and explain how its hollow-shaft structure, EtherCAT connectivity, and flexible mounting options support the development of humanoid robots, drones, optical platforms, and precision automation equipment.
 How Does the HONPINE HPG Backlash-Free Planetary Rotary Actuator Balance CNC Accuracy and Rigidity?Discover the HONPINE HPG precision backlash-free planetary rotary actuator for CNC rotary tables. Explore positioning accuracy, torsional rigidity, low backlash, and drive selection.
 Why Are DD Torque Motors Ideal for High-End Five-Axis Rotary Tables?Choosing the right drive mechanism is critical to the performance of a five-axis rotary table. Worm gears, cam roller drives, harmonic reducers, RV cycloidal reducers, and DD torque motors each offer different advantages in positioning accuracy, torsional stiffness, speed, and cost. For high-end CNC machining, the challenge is not simply achieving low backlash, but maintaining accuracy under cutting loads and during continuous multi-axis motion. This article compares five common drive technologies and explains why direct-drive torque motors are an attractive option for applications requiring high dynamic response, reduced transmission errors, and consistent machining performance.